


RoboSkills is a low-cost, minimal set of agent workflows and tools for robotics.
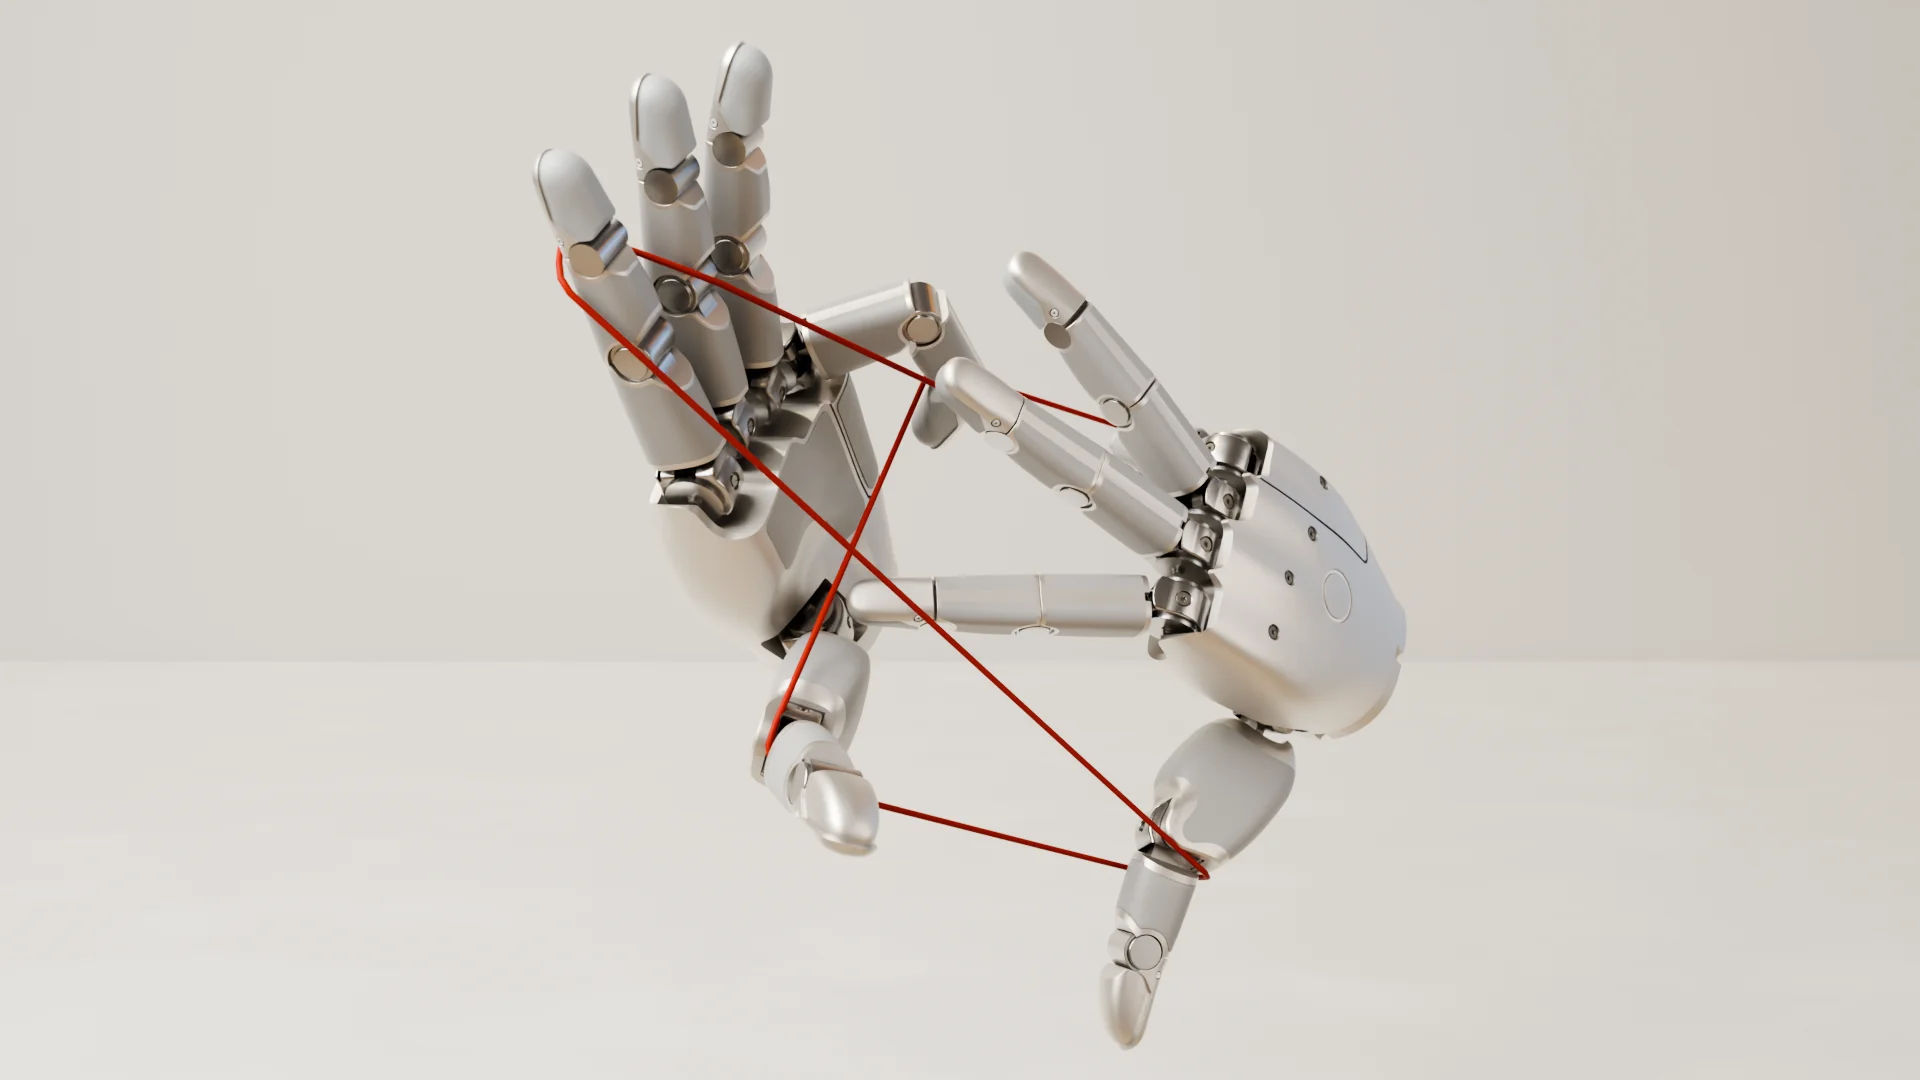
Sharpa hands playing cat's cradle, reconstructed from a human video.
 Auto Research Improve policies and reusable skills through repeated simulation experiments. Setting: Auto-research; no direct privileged simulator state in the policy API. |
 Agent as Policy An LLM observes an episode and chooses actions turn by turn. Setting: Zero/one-shot demonstrations; no auto-research. |
 Agentic Simulation Solve simulation tasks from natural-language instructions. Setting: Privileged simulator information available. |
 Real2Sim Build interactive simulations from demonstrations. Setting: Physics simulation included. |
 Motion Generation One agent turns a text, image or video request into a motion video. Setting: Kinematic motion and rendering; no physics. |
With suitable tools, agents reach comparable performance on fewer, cheaper tokens.
| Real2Sim · DexYCB potted meat can | Motion Generation · Tennis serve |
|---|---|
| Cost $0.09. 11% of Codex. | Cost $0.00. 0% of Claude Code. |
 |
 |
| Agent as Policy · RoboDojo stack blocks | Auto Research · RoboDojo press by number |
| Cost $0.16 with DeepSeek. 7% of Claude Code. Both 5/5 on 5 seeds. | Cost $0.14 with DeepSeek. 13% of Claude Code. Both 3/3 on 3 seeds. |
 |
 |
We commit to keeping each workflow under 1,000 lines of code.
| Tool | Does | Reference |
|---|---|---|
 RoboKit |
kinematics, motion planning, robot hands | Code |
| GraspKit |
learned grasps | Code |
 SAM 3 |
text → masks | Paper · Code |
| SAM 3D |
image → object mesh | Paper · Code |
 MoGe |
image → depth | Paper · Code |
 GeoCalib |
image → gravity | Paper · Code |
 HaWoR |
video → hand motion | Paper · Code |
| WiLoR |
image → hands (MANO) | Paper · Code |
 GVHMR |
video → human motion | Paper · Code |
 Kimodo |
text → G1 or human motion | Paper · Code |
 Blender |
rendering | Site · Code |
 CoACD |
mesh → convex collision parts | Paper · Code |
 MuJoCo |
physics, IK, contact feedback, rendering | Paper · Code |
Requires Python 3.10 or newer:
uv add roboskills # or: pip install roboskillsThe workflows run from a clone (git clone https://github.com/openrobokit/roboskills && cd roboskills && uv sync); each
workflow's README goes on from there.