


RetargetingKit maps live or recorded human motion to robot hands, arms, and humanoids using RoboKit optimization and neural hand models.
The two main applications are:
- 🎮 Real-time teleoperation
- ⚡ Offline retargeting in parallel
Real-time teleoperation with dexterous hands and humanoids.
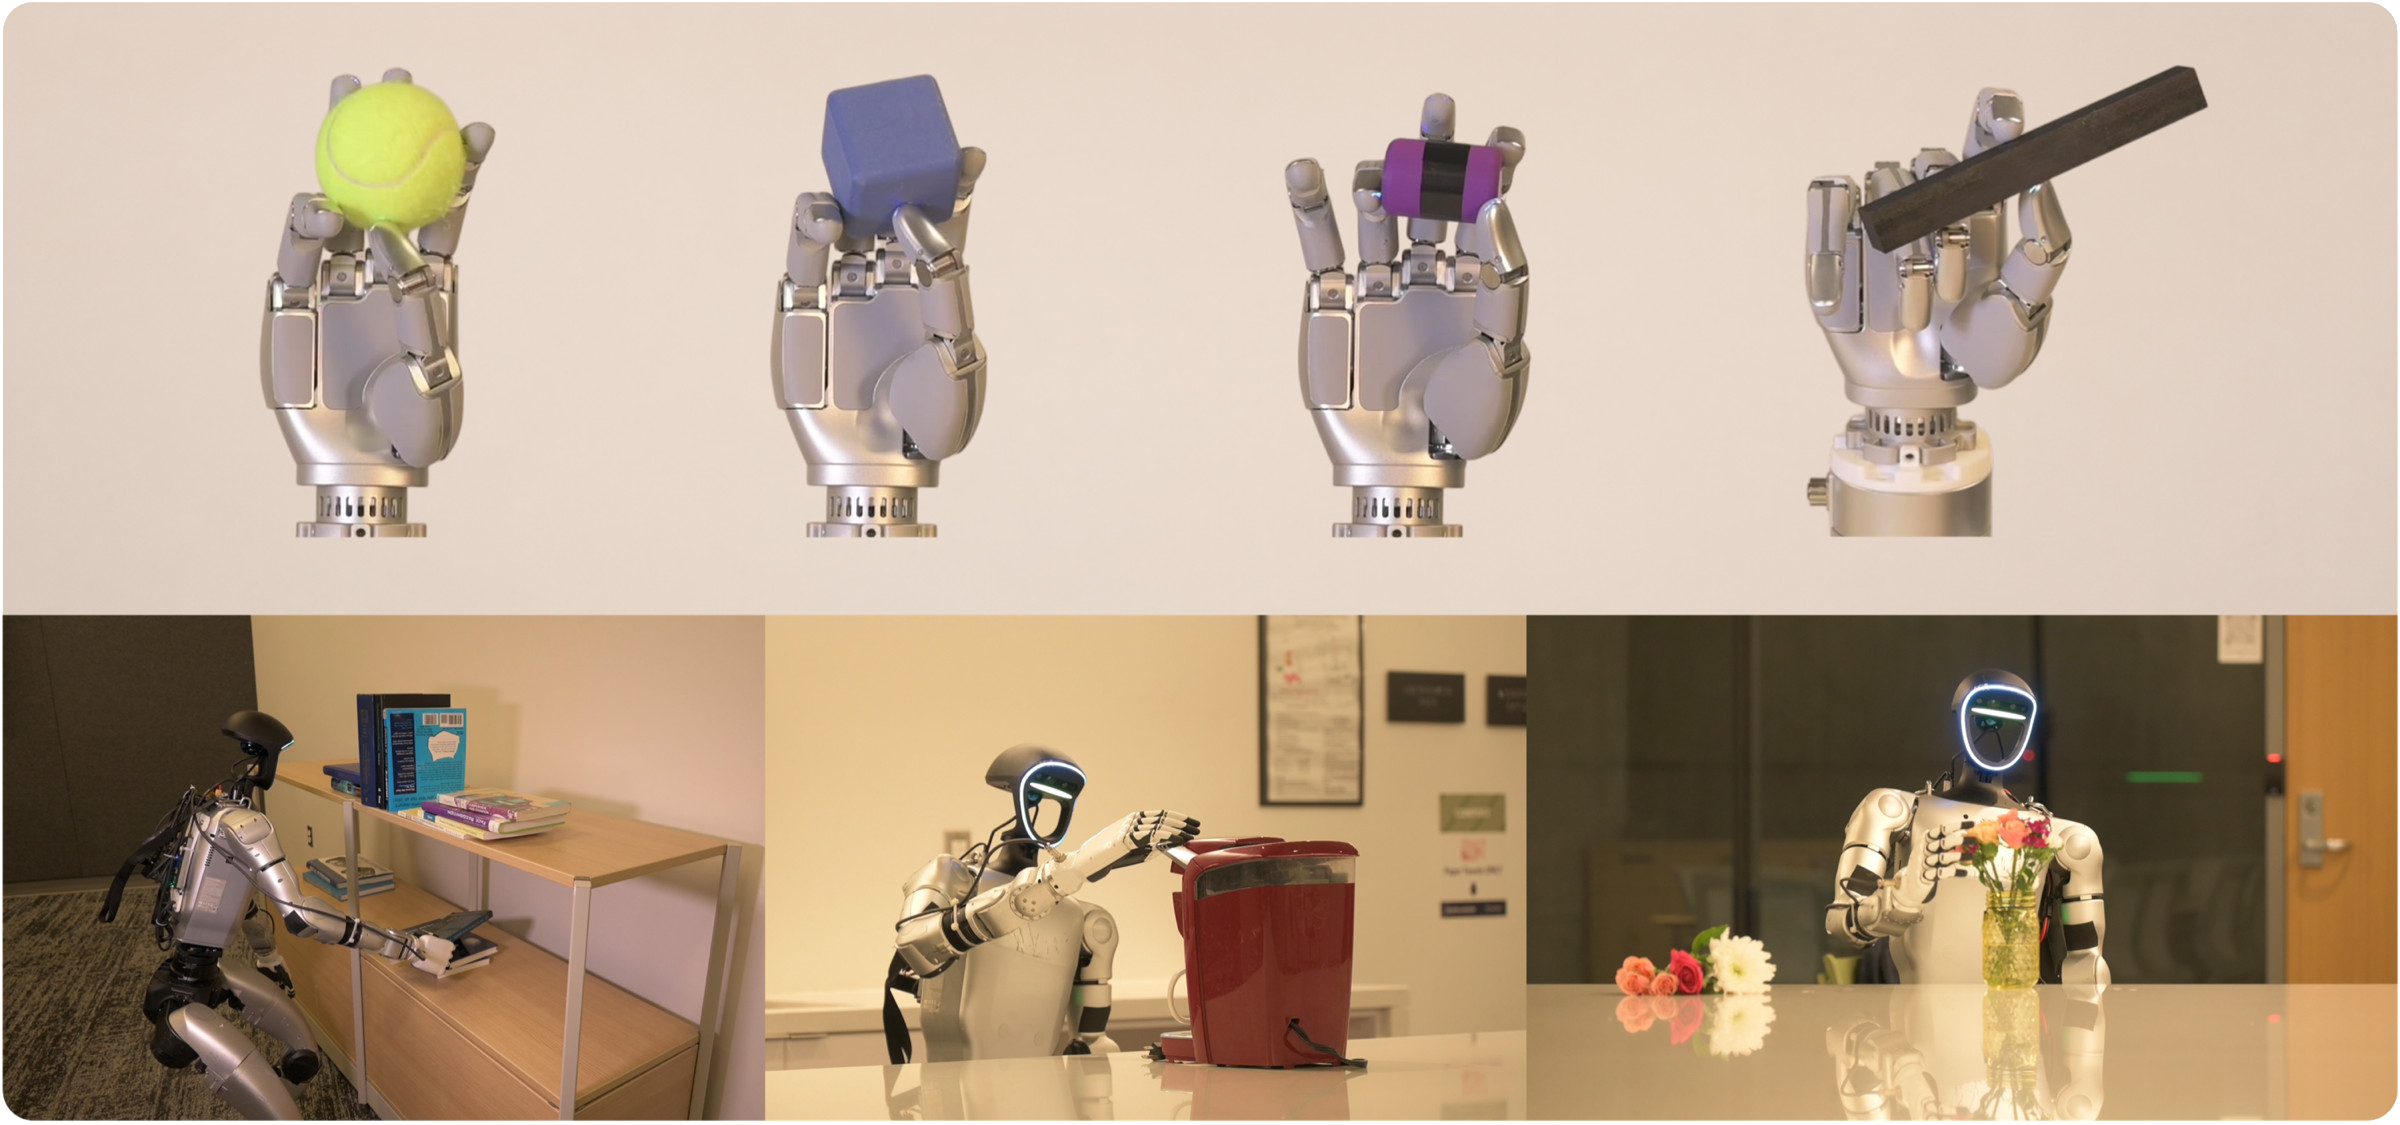
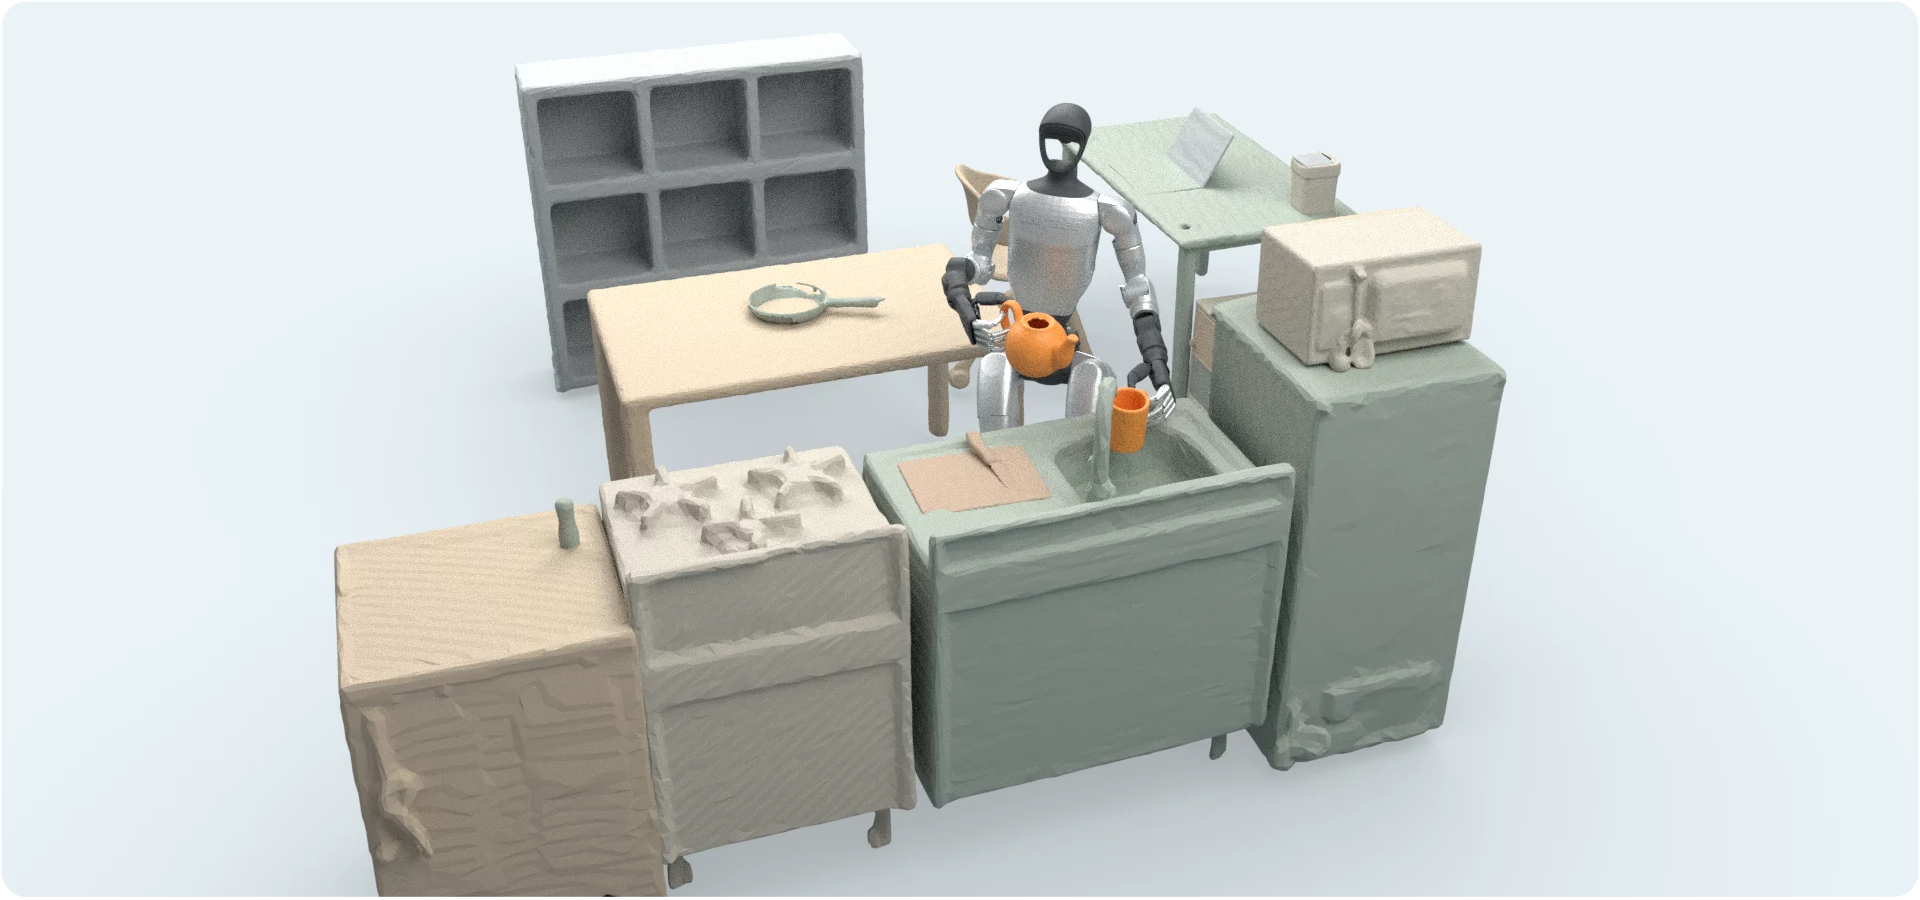
Body-and-hand retargeting in a furnished scene.
Requires Python 3.10 or newer:
uv add retargetingkit # or: pip install retargetingkitSee Installation for source installs, extras, and asset access.
Explore recorded motions and robot presets in the gallery examples.
flowchart LR
    Source["`Source
    *VR · gloves · mocap · recordings*`"]
    Retargeter["`Retargeter
    *Optimization + Neural*`"]
    Target["`Target
    *Viser · robot hardware*`"]
    Source -- "Frame: hand · arm · body" --> Retargeter
    Retargeter -- "Command: robot joints · base pose" --> Target
    classDef endpoint fill:#dbeafe,stroke:#2563eb,color:#111827
    classDef solver fill:#dbc8ea,stroke:#8163a1,stroke-width:2px,color:#111827
    class Source,Target endpoint
    class Retargeter solver
| Component | Role | Read more |
|---|---|---|
| Source | Read a device or recording and produce a canonical frame. | Sources |
| Frame | Represent human hand, arm, or body motion. | Frames |
| Retargeter | Solve hand, arm, or body motion using RoboKit. | Interfaces |
| Command | Carry robot joint positions and an optional base pose. | Commands |
| Target | Preview commands or send them to a robot. | Targets |
See the framework overview for frames, commands, and named rigs.