




GraspKit is an end-to-end toolkit for manipulation across various robot embodiments, including grippers and dexterous hands. It synthesizes grasps, plans trajectories, trains policies, and deploys them in simulation or on real robots; it is built on top of RoboKit.
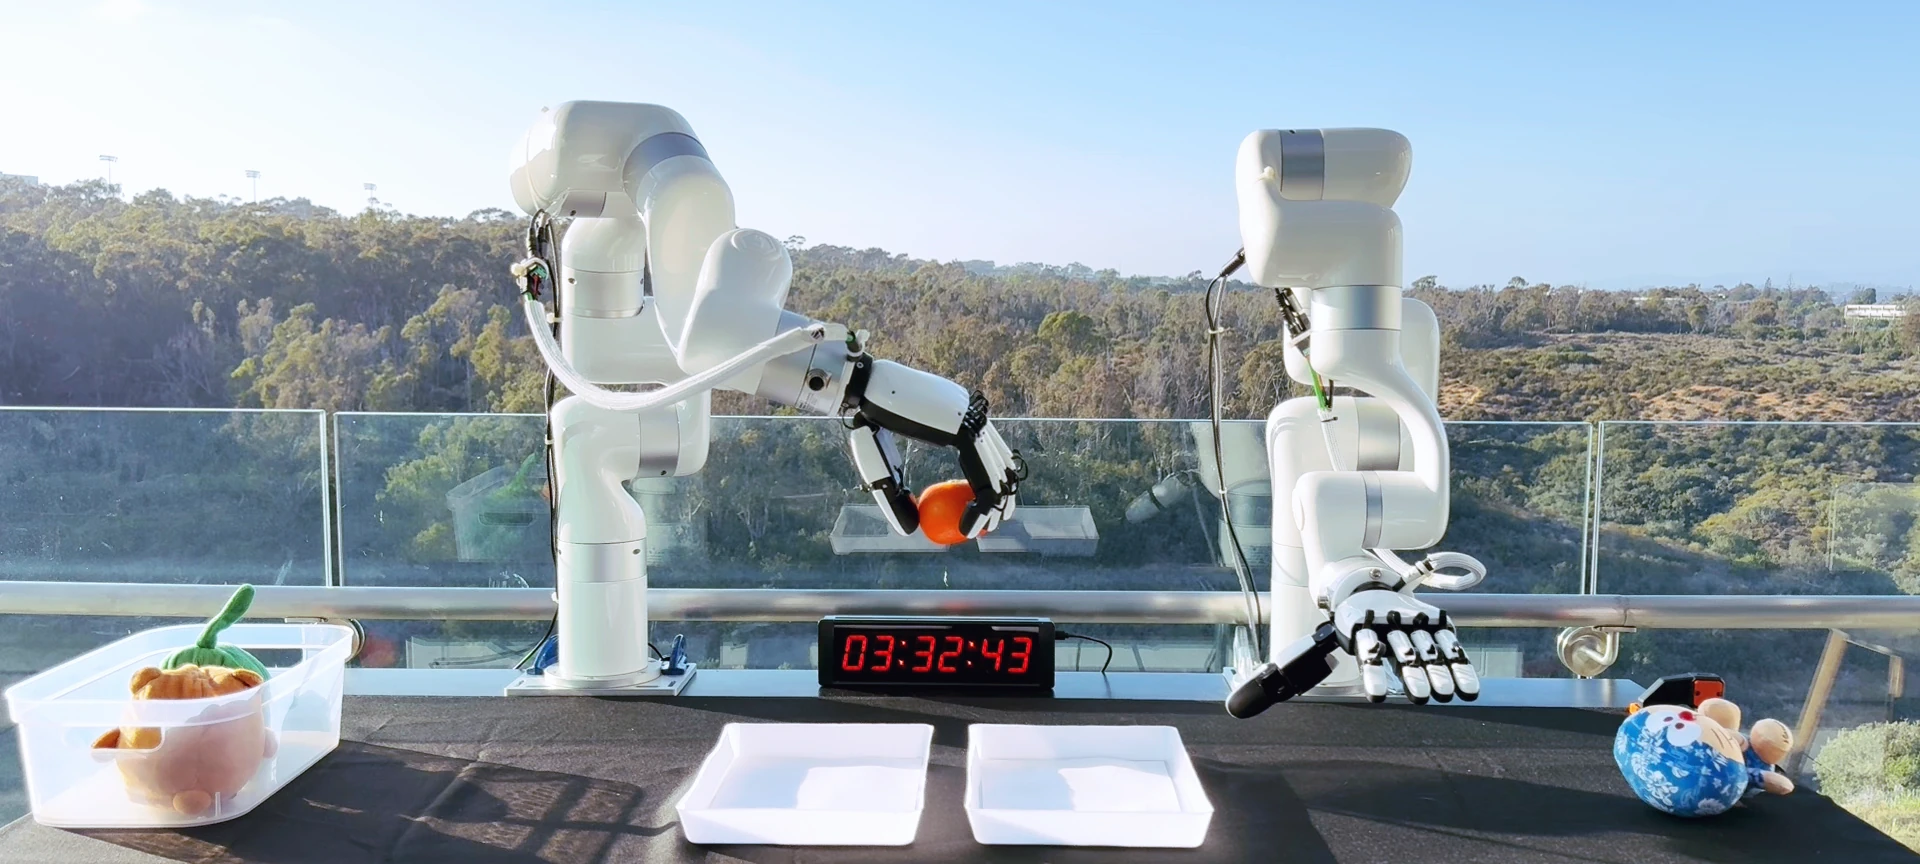
Real-world grasping with dexterous robot hands in San Diego.
Requires Python 3.10–3.14 (the full pipeline with ManiSkill and spconv: 3.10–3.12):
uv add graspkit # or: pip install graspkitSee Installation for source installs, PyTorch options, and asset access.
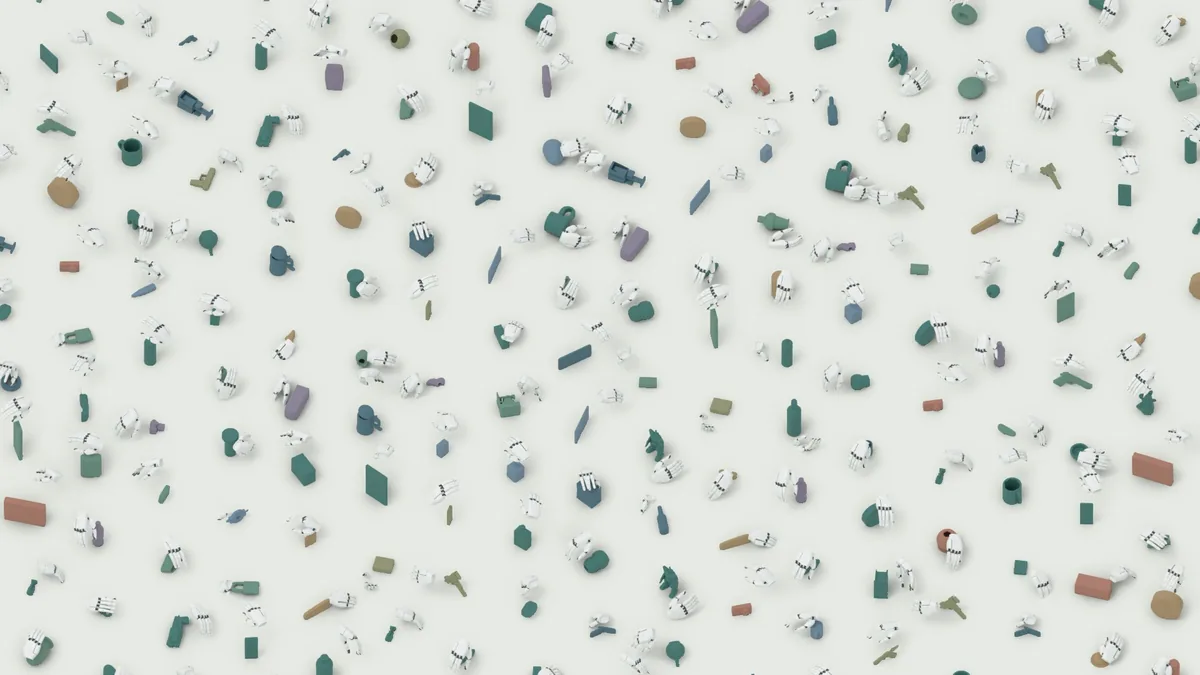 Fast grasp optimization |
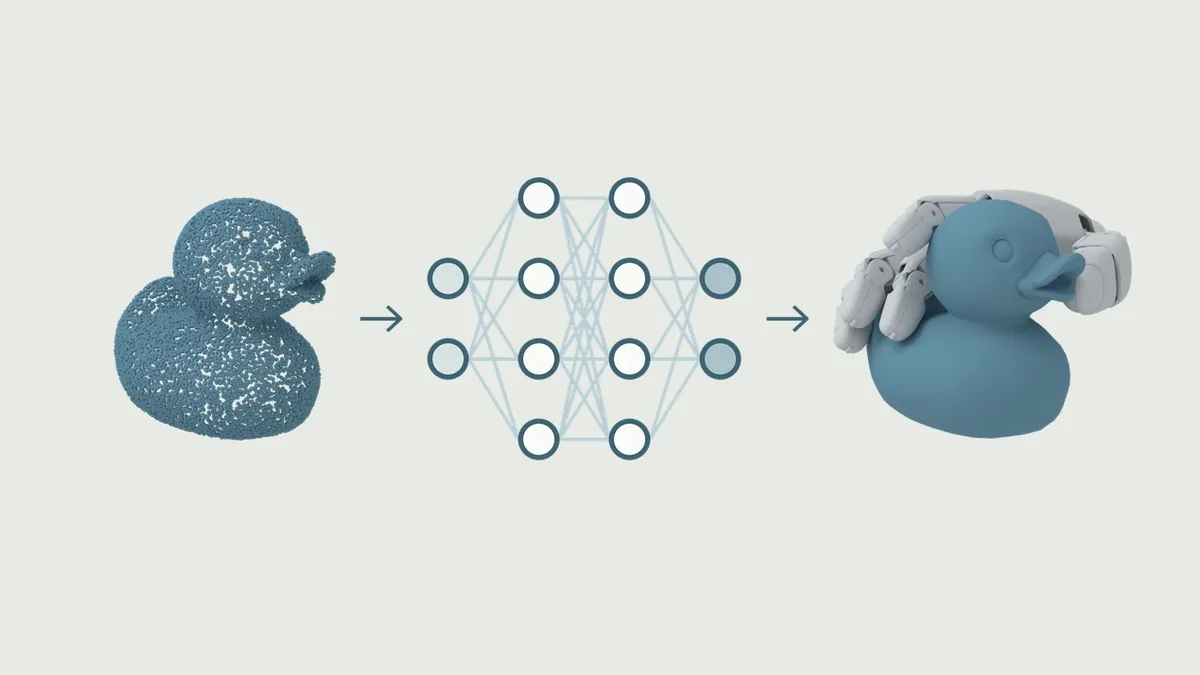 Policy learning |
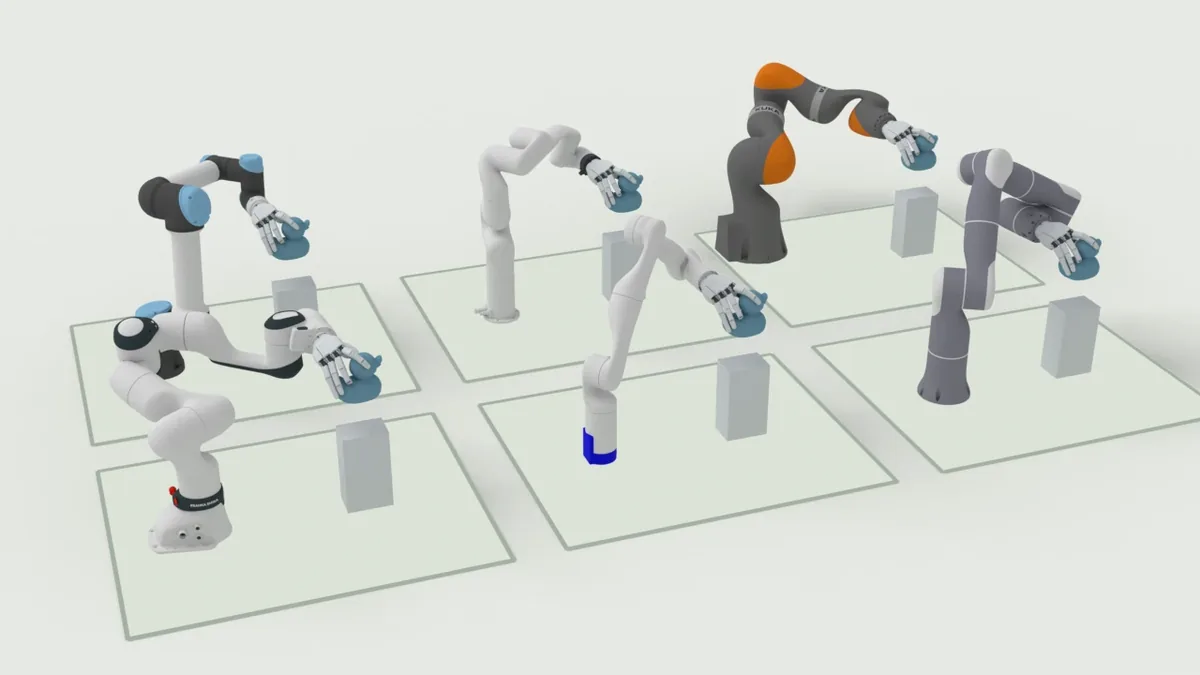 All arms, all hands |
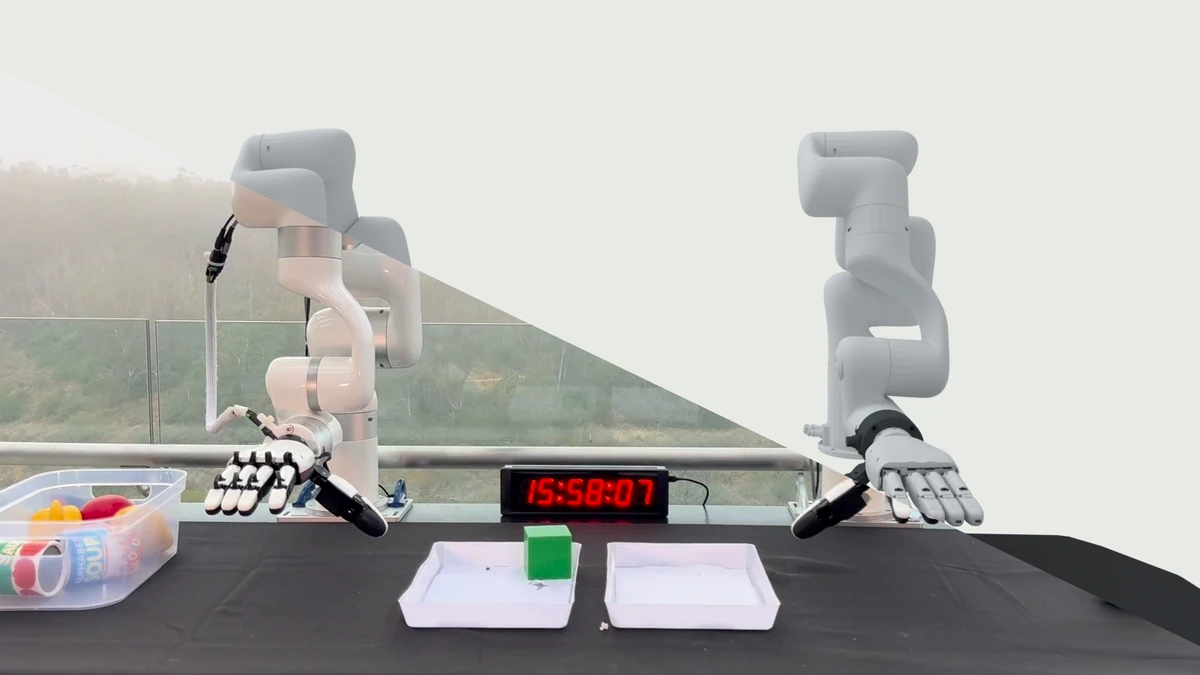 Real-world robustness |
Explore robot presets and optimized grasps in the interactive gallery.
For each scene, GraspKit optimizes and plans grasps on the GPU and renders the camera's point cloud. A policy trained on these pairs maps point clouds to grasp trajectories, in simulation or on real robots.
| Stage | Role | Read more |
|---|---|---|
| Grasp optimization | Generate grasps, plan motions, and optionally validate them in simulation. | Grasp optimization |
| Rendering | Render point-cloud observations for the same scenes. | Pipeline |
| Data processing | Join observations and grasps into policy training data. | Pipeline |
| Training | Train a grasp policy on the processed data. | Training |
| Deployment | Run a trained policy in simulation or on a real robot. | Sim, real |
See the core overview for the full stage graph and artifacts.