
📄 (Korean)
An open-source framework for connecting LLM's peripherals.
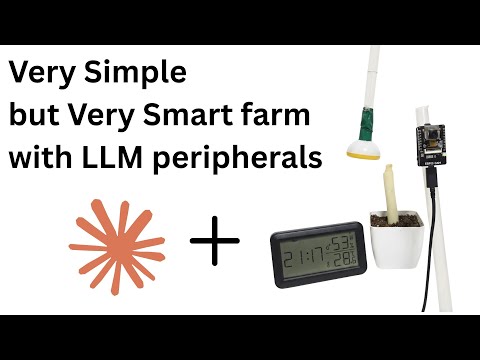

LLMs can use digital tools (code interpreters, search engines, databases) via the Model Context Protocol (MCP). But connecting them to physical hardware—cameras, motors, sensors—is complicated.

SABA provides a simple way for LLMs to control physical devices. Define your hardware's purpose in natural language, and the LLM figures out the rest.
Plug & Play. Configure Wi-Fi once, and your device is ready. No schemas. Just describe what your device does in natural language. Intent-based. Instead of "rotate motor 50°," you define "open_living_room_curtain." LLM-native. Works seamlessly with Claude, GPT, and other LLMs via MCP.
Your devices become tools that LLMs can autonomously use during conversations—just like they use code interpreters or search engines.
Connect your device, configure Wi-Fi/MQTT once, and it's ready. The LLM can immediately understand and control it through SABA's core server.
A motor can do thousands of things. What matters is the intent:
water_plant(not "activate pump for 3 seconds")open_curtain(not "rotate motor 90 degrees")press_coffee_button(not "extend actuator 2cm")
The LLM understands the purpose from the name. No complex configurations needed.
From simple motors and sensors to cameras and complex actuators. ESP32-based for affordability, with plans to support more platforms.
Version 0 A
Version 0.1 - Proof of concept
What works:
- ✅ ESP32 device SDK with automatic provisioning
- ✅ MCP bridge server for Claude Desktop integration
- ✅ Camera, motor, sensor, and LED control examples
- ✅ Web-based projection manager
What's next:
- Security (TLS/encryption)
- Performance optimization
- Better documentation and tutorials
- Event-driven architecture for proactive agents
- More example projects
Hardware: Device SDK
Server: Core Server
Any help, ideas, and collaborations are welcome.
Contact me
- Email: gyeongmingim478@gmail.com
- Instagram: gyeongmin116
Apache License 2.0 - See LICENSE file for details.