

SWE B.S. @ Loyola Chicago, December 2027 graduation. U.S. citizen, clearance-eligible. Looking for a Summer 2027 internship in flight software, firmware, or GNC.
Attitude estimation, flight controllers, and vehicle dynamics — multirotors, eVTOL, and anything that has to know which way is up without being told.
antoniogarcia41624@gmail.com · LinkedIn
ArduPilot — the autopilot behind a large share of commercial and research UAVs.
- #34890 — reported a link
failure that blocks SITL builds on current Xcode, traced to a
PACKEDstruct placing a pointer at a 4-byte-aligned offset after Apple removed the classic linker. - #34924 — reviewed the fix on the toolchain that reproduces the bug, including flying it in SITL.
- #34928 — follow-up PR replacing an unbounded compiler-version check with a configure-time linker probe, so a dead flag stops being passed to linkers that no longer accept it. (open)
attitude-estimator — complementary filter estimating roll and pitch from gyro and accelerometer, scored against ArduCopter SITL ground truth. 3.75° roll / 6.32° pitch RMS over a 176 s flight, against 52°/156° for raw gyro integration. Includes the script that generates the flight data, and a writeup of the two mistakes that nearly invalidated the results.
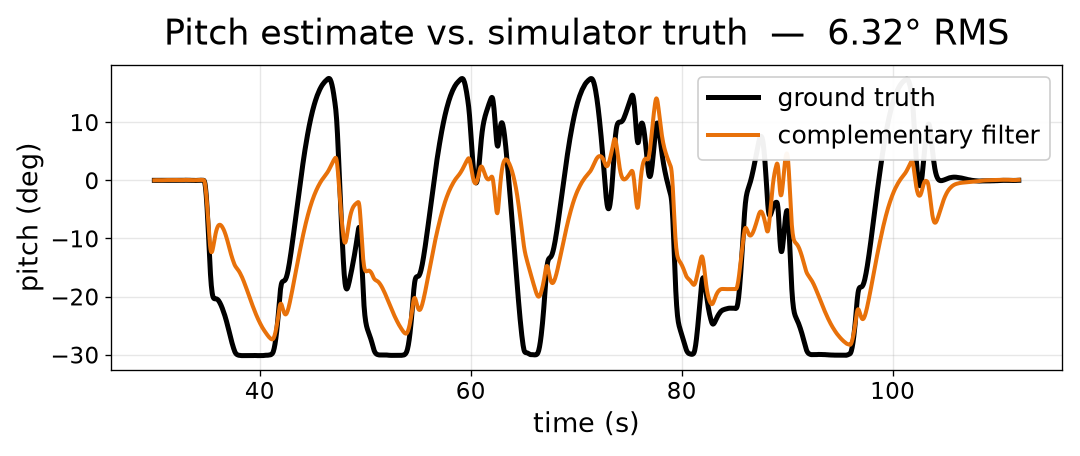
- Bringing the attitude estimator up on a Teensy 4.1 with a real IMU. The filter is already ported to allocation-free C and reproduces the Python results exactly; what remains is the I2C driver and the sampling loop
- Working through ArduPilot issues to get deeper into the codebase
Python · C · ArduPilot · SITL · MAVLink / pymavlink · waf · Git