diff --git a/README.md b/README.md
index 63692ee..72892f0 100644
--- a/README.md
+++ b/README.md
@@ -1,10 +1,12 @@
-  +

 +
 +
RetargetingKit maps live or recorded human motion to robot hands, arms, and humanoids using [RoboKit](https://github.com/openrobokit/robokit) optimization and neural hand models.
@@ -14,8 +16,19 @@ The two main applications are:
- 🎮 **Real-time teleoperation**
- ⚡ **Offline retargeting in parallel**
+
+ 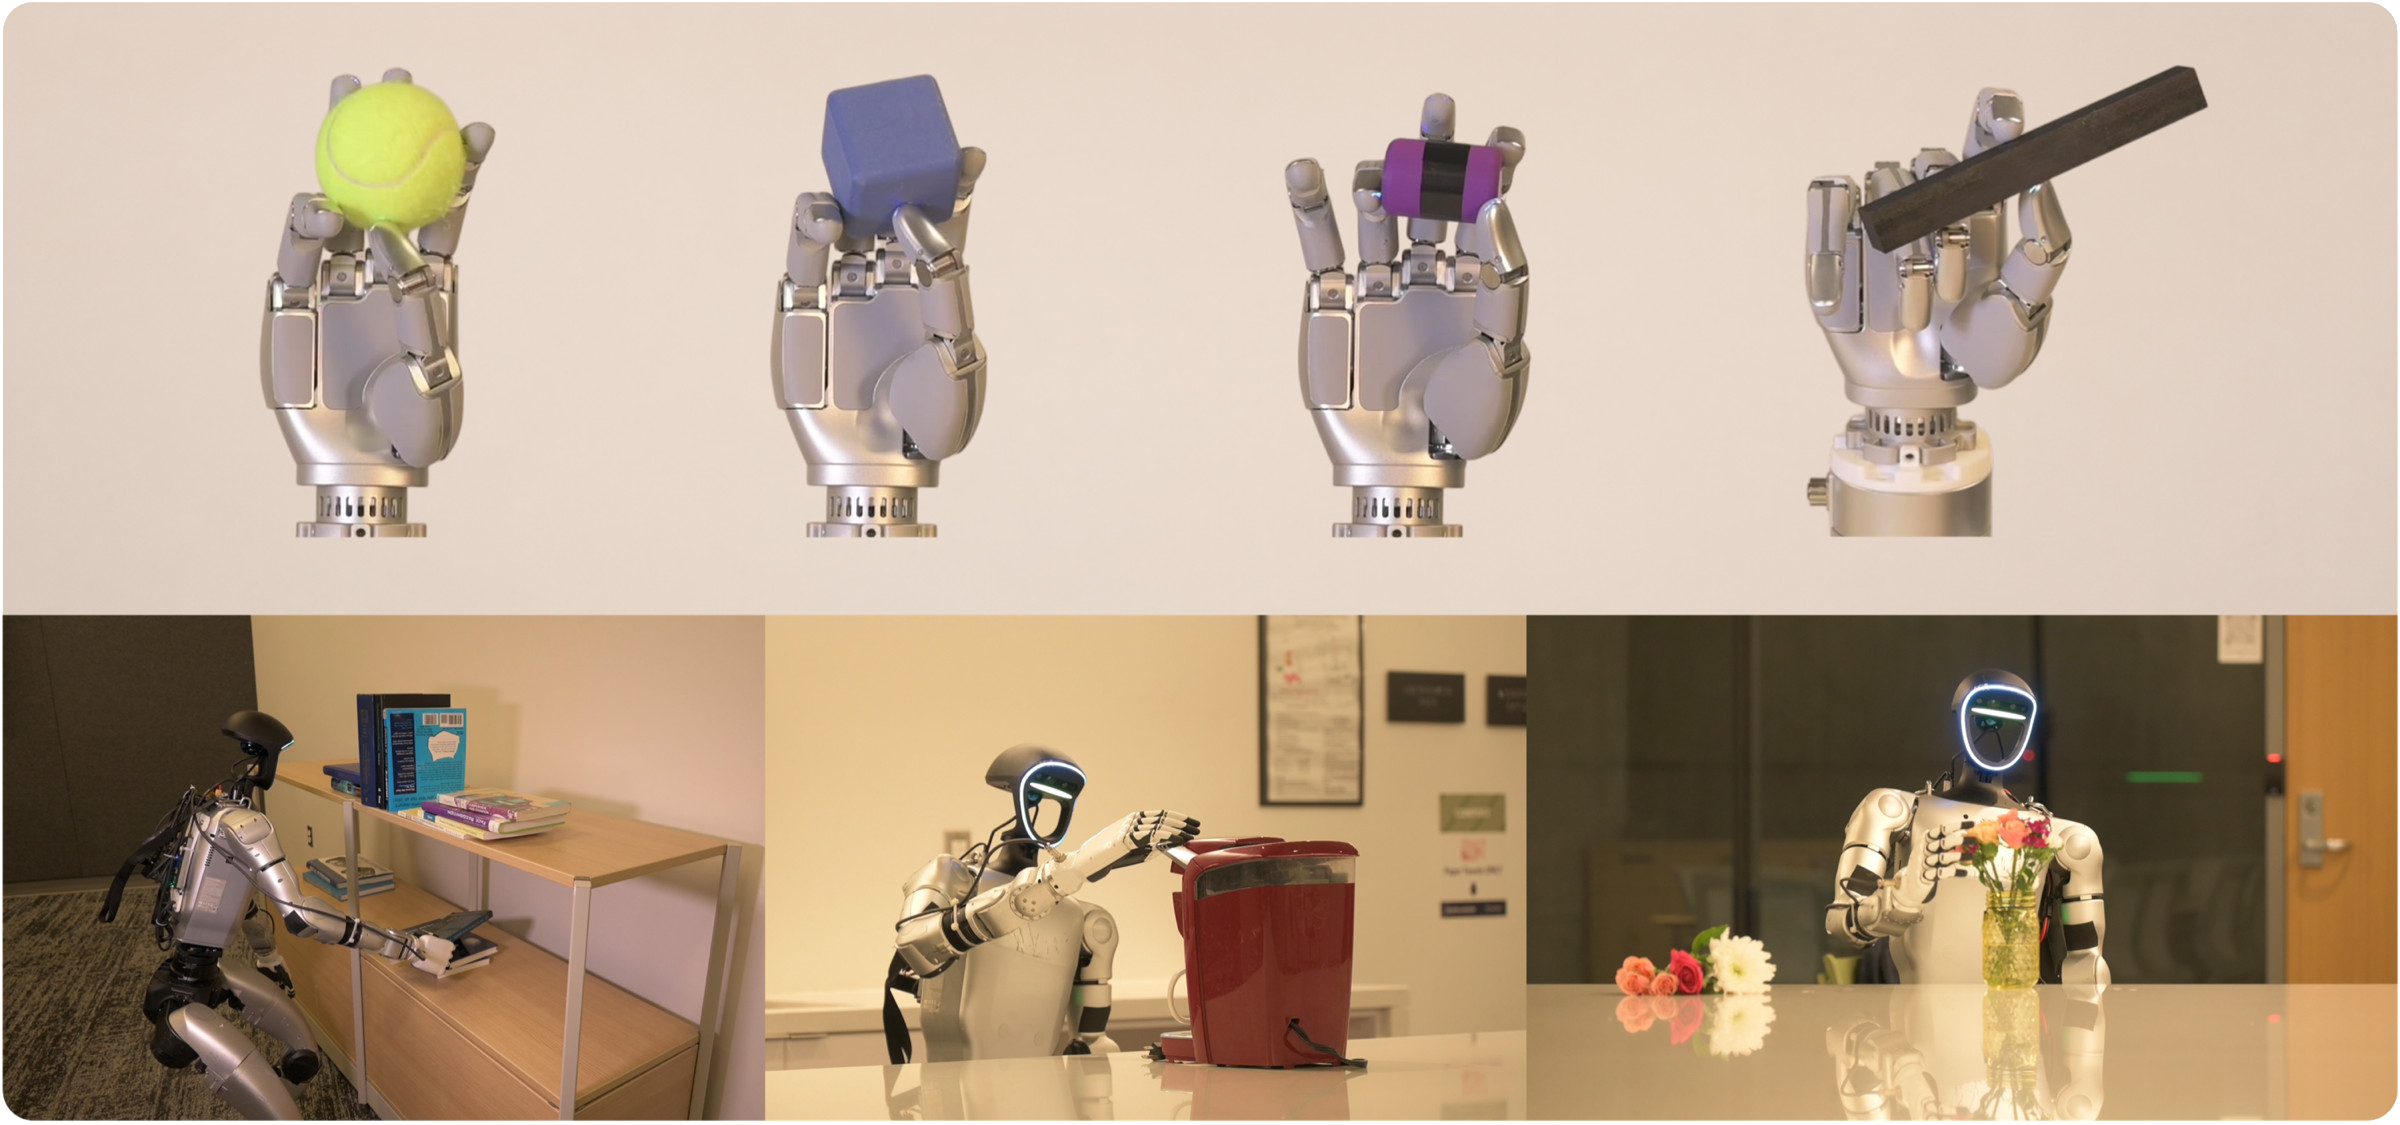
+ Real-time teleoperation with dexterous hands and humanoids.
+
+
+
+ 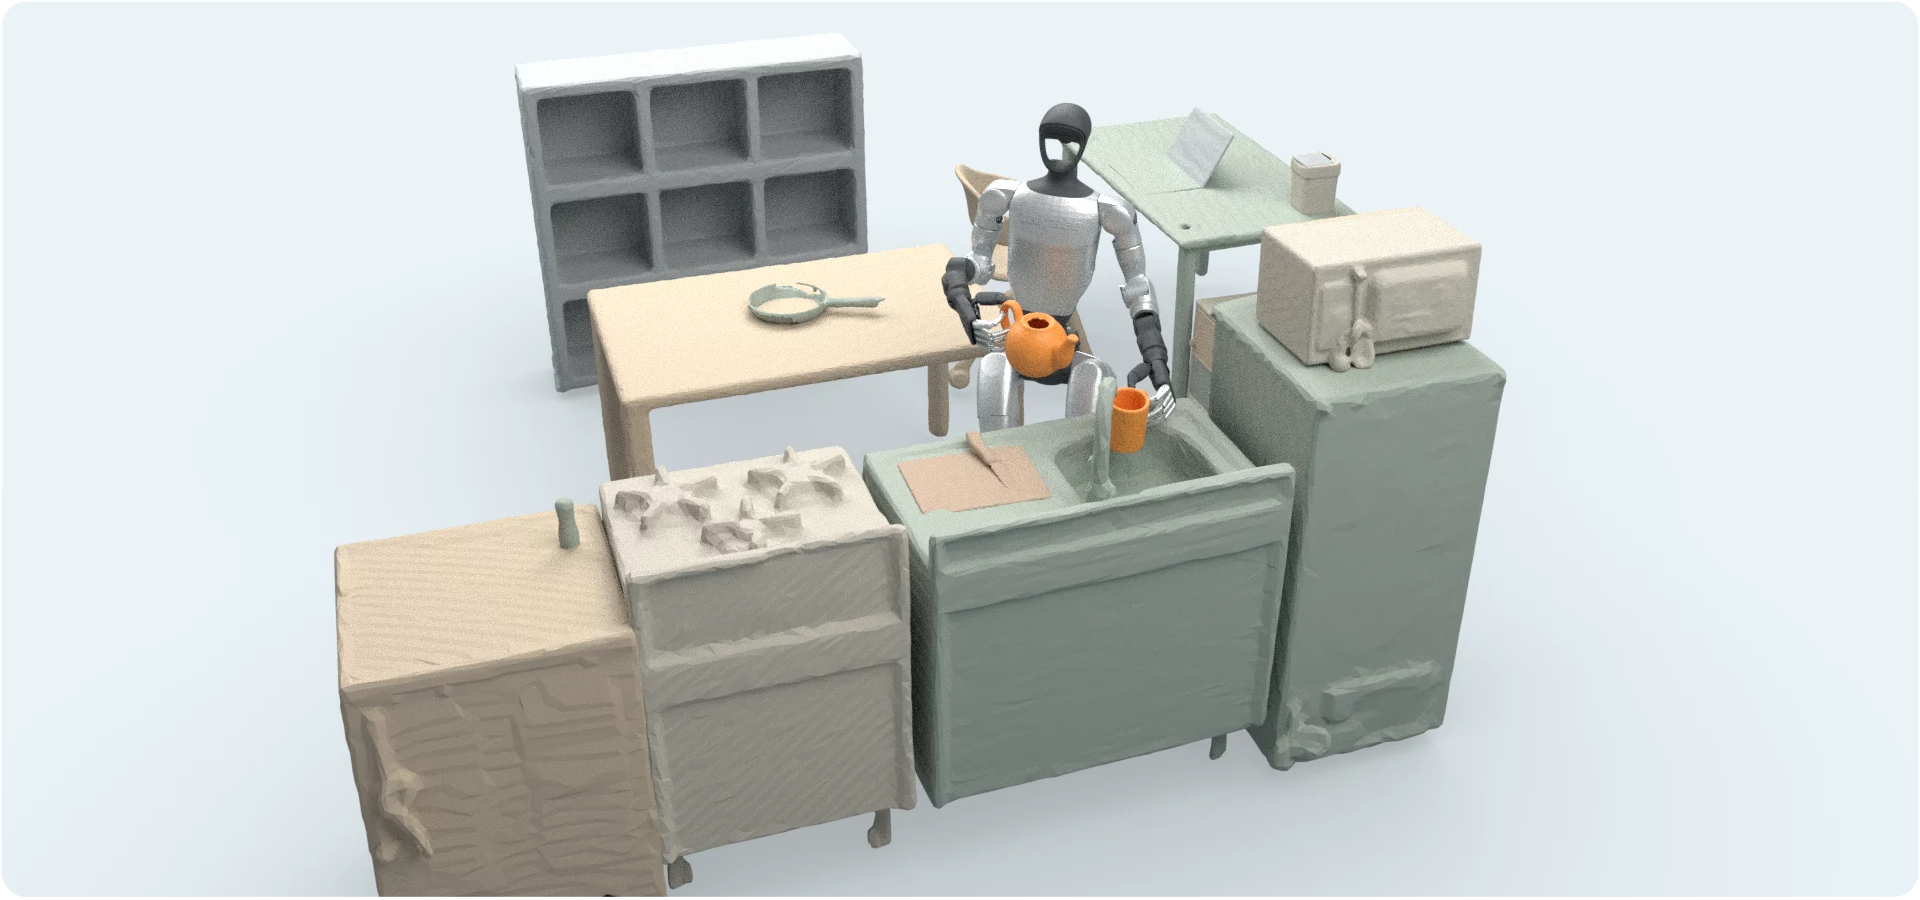
+ Body-and-hand retargeting in a furnished scene.
+
+
## Quick links
+- [Homepage](https://openrobokit.com/retargetingkit)
- [Docs](https://github.com/openrobokit/retargetingkit/blob/main/docs/guide/overview.md)
- [Quickstart](https://github.com/openrobokit/retargetingkit/blob/main/docs/guide/quickstart.md)
- [Installation](https://github.com/openrobokit/retargetingkit/blob/main/docs/guide/installation.md)
@@ -35,34 +48,46 @@ See [Installation](https://github.com/openrobokit/retargetingkit/blob/main/docs/
diff --git a/docs/assets/built-in-tasks/full-body-geometry.webp b/docs/assets/built-in-tasks/full-body-geometry.webp
deleted file mode 100644
index 495c026..0000000
Binary files a/docs/assets/built-in-tasks/full-body-geometry.webp and /dev/null differ
diff --git a/docs/assets/built-in-tasks/full-body-retargeting.webp b/docs/assets/built-in-tasks/full-body-retargeting.webp
deleted file mode 100644
index 8b7500b..0000000
Binary files a/docs/assets/built-in-tasks/full-body-retargeting.webp and /dev/null differ
diff --git a/docs/assets/built-in-tasks/hand-geometry-sim.webp b/docs/assets/built-in-tasks/hand-geometry-sim.webp
deleted file mode 100644
index 6c2ea64..0000000
Binary files a/docs/assets/built-in-tasks/hand-geometry-sim.webp and /dev/null differ
diff --git a/docs/assets/built-in-tasks/hand-retargeting.webp b/docs/assets/built-in-tasks/hand-retargeting.webp
deleted file mode 100644
index 6c1ba29..0000000
Binary files a/docs/assets/built-in-tasks/hand-retargeting.webp and /dev/null differ
diff --git a/docs/assets/built-in-tasks/humanoid-geometry.webp b/docs/assets/built-in-tasks/humanoid-geometry.webp
deleted file mode 100644
index a793033..0000000
Binary files a/docs/assets/built-in-tasks/humanoid-geometry.webp and /dev/null differ
diff --git a/docs/assets/built-in-tasks/humanoid-retargeting.webp b/docs/assets/built-in-tasks/humanoid-retargeting.webp
deleted file mode 100644
index 337867d..0000000
Binary files a/docs/assets/built-in-tasks/humanoid-retargeting.webp and /dev/null differ
diff --git a/docs/assets/retargetingkit-banner.webp b/docs/assets/retargetingkit-banner.webp
deleted file mode 100644
index 57a5a13..0000000
Binary files a/docs/assets/retargetingkit-banner.webp and /dev/null differ
diff --git a/docs/assets/sources/cloudxr-web-client-howto.png b/docs/assets/sources/cloudxr-web-client-howto.png
deleted file mode 100644
index 232c08e..0000000
Binary files a/docs/assets/sources/cloudxr-web-client-howto.png and /dev/null differ
diff --git a/docs/assets/sources/cloudxr_accept_cert_accepted.png b/docs/assets/sources/cloudxr_accept_cert_accepted.png
deleted file mode 100644
index c93954f..0000000
Binary files a/docs/assets/sources/cloudxr_accept_cert_accepted.png and /dev/null differ
diff --git a/docs/assets/sources/disable_proximity_sensor.png b/docs/assets/sources/disable_proximity_sensor.png
deleted file mode 100644
index 6d4eb0c..0000000
Binary files a/docs/assets/sources/disable_proximity_sensor.png and /dev/null differ
diff --git a/docs/assets/sources/sidequest_tool.png b/docs/assets/sources/sidequest_tool.png
deleted file mode 100644
index d77c502..0000000
Binary files a/docs/assets/sources/sidequest_tool.png and /dev/null differ
diff --git a/docs/assets/sources/vision-pro-tracking-streamer-app.jpg b/docs/assets/sources/vision-pro-tracking-streamer-app.jpg
deleted file mode 100644
index 9acebdb..0000000
Binary files a/docs/assets/sources/vision-pro-tracking-streamer-app.jpg and /dev/null differ
diff --git a/docs/assets/sources/vision-pro-tracking-streamer-start.jpg b/docs/assets/sources/vision-pro-tracking-streamer-start.jpg
deleted file mode 100644
index 2568921..0000000
Binary files a/docs/assets/sources/vision-pro-tracking-streamer-start.jpg and /dev/null differ
diff --git a/docs/assets/sources/xrobotoolkit-pico-fullbody-settings.jpeg b/docs/assets/sources/xrobotoolkit-pico-fullbody-settings.jpeg
deleted file mode 100644
index 380bd2f..0000000
Binary files a/docs/assets/sources/xrobotoolkit-pico-fullbody-settings.jpeg and /dev/null differ
diff --git a/docs/guide/arm_retargeting.md b/docs/guide/arm_retargeting.md
index 4be24a8..9c75e5f 100644
--- a/docs/guide/arm_retargeting.md
+++ b/docs/guide/arm_retargeting.md
@@ -1,5 +1,7 @@
# Arm Retargeting
+
+
Map a tracked wrist to an xArm6 or xArm7 end effector. The arm solver uses RoboKit inverse kinematics with position, orientation, joint-limit, and smoothness terms.
## How Retargeting Works
diff --git a/docs/guide/full_body_retargeting.md b/docs/guide/full_body_retargeting.md
index 4549eb0..b056a83 100644
--- a/docs/guide/full_body_retargeting.md
+++ b/docs/guide/full_body_retargeting.md
@@ -1,7 +1,8 @@
# Full-Body Retargeting
-| Body, hand, and object interaction. | Body and hand motion in a furnished scene. |
+|  |  |
| --- | --- |
+| Body, hand, and object interaction. | Body and hand motion in a furnished scene. |
Retarget body motion, articulated fingers, and object interaction together to a G1 with Inspire hands. RetargetingKit loads SAGA or ParaHome clips; RoboKit solves the robot motion and object poses.
diff --git a/docs/guide/hand_retargeting.md b/docs/guide/hand_retargeting.md
index d4aeec1..b6156b4 100644
--- a/docs/guide/hand_retargeting.md
+++ b/docs/guide/hand_retargeting.md
@@ -1,7 +1,8 @@
# Hand Retargeting
-| Hand motion on a robot assembly. | Hand-object contact refinement. |
+|  |  |
| --- | --- |
+| Hand motion on a robot assembly. | Hand-object contact refinement. |
Map human hand motion to robot joint positions with RoboKit's online or offline optimization. Start with a recorded example, then connect a [Manus glove](../reference/sources/manus.md) or [Apple Vision Pro](../reference/sources/vision_pro.md).
diff --git a/docs/guide/humanoid_retargeting.md b/docs/guide/humanoid_retargeting.md
index f0c9ca6..1b57d40 100644
--- a/docs/guide/humanoid_retargeting.md
+++ b/docs/guide/humanoid_retargeting.md
@@ -1,7 +1,8 @@
# Humanoid Retargeting
-| Human motion mapped to a humanoid. | Humanoid motion on terrain. |
+|  |  |
| --- | --- |
+| Human motion mapped to a humanoid. | Humanoid motion on terrain. |
Map recorded or live body motion to G1 at 50 Hz. The runtime sends robot root pose and joint positions to its configured targets; the SONIC target derives joint velocities for whole-body control.
diff --git a/docs/guide/neural_hand_retargeting.md b/docs/guide/neural_hand_retargeting.md
index 9b7d734..c9c69c8 100644
--- a/docs/guide/neural_hand_retargeting.md
+++ b/docs/guide/neural_hand_retargeting.md
@@ -1,5 +1,7 @@
# Neural Hand Retargeting
+
+
Train a model for one robot hand, then map wrist-local MANO-21 keypoints to joint positions in URDF order. Curated checkpoints support Allegro, Sharpa Wave, and XHand.
## How Inference Works
diff --git a/docs/guide/overview.md b/docs/guide/overview.md
index 7d39782..4ffdfc3 100644
--- a/docs/guide/overview.md
+++ b/docs/guide/overview.md
@@ -1,4 +1,6 @@
-
+
+
+[](https://openrobokit.com/retargetingkit)
RetargetingKit maps human motion to robot hands, arms, and humanoids. It combines RoboKit optimization with neural hand models for recorded motion and real-time teleoperation.
@@ -37,17 +39,17 @@ flowchart LR
## Features
-| [](hand_retargeting.md) | [](hand_retargeting.md#inspect-object-contact) |
-| --- | --- |
-| **[Hand retargeting](hand_retargeting.md)** Map tracked hand motion to robot joints. | **[Geometry-aware hand retargeting](hand_retargeting.md#inspect-object-contact)** Refine hands against object geometry. |
+| [](hand_retargeting.md) | [](hand_retargeting.md#inspect-object-contact) | [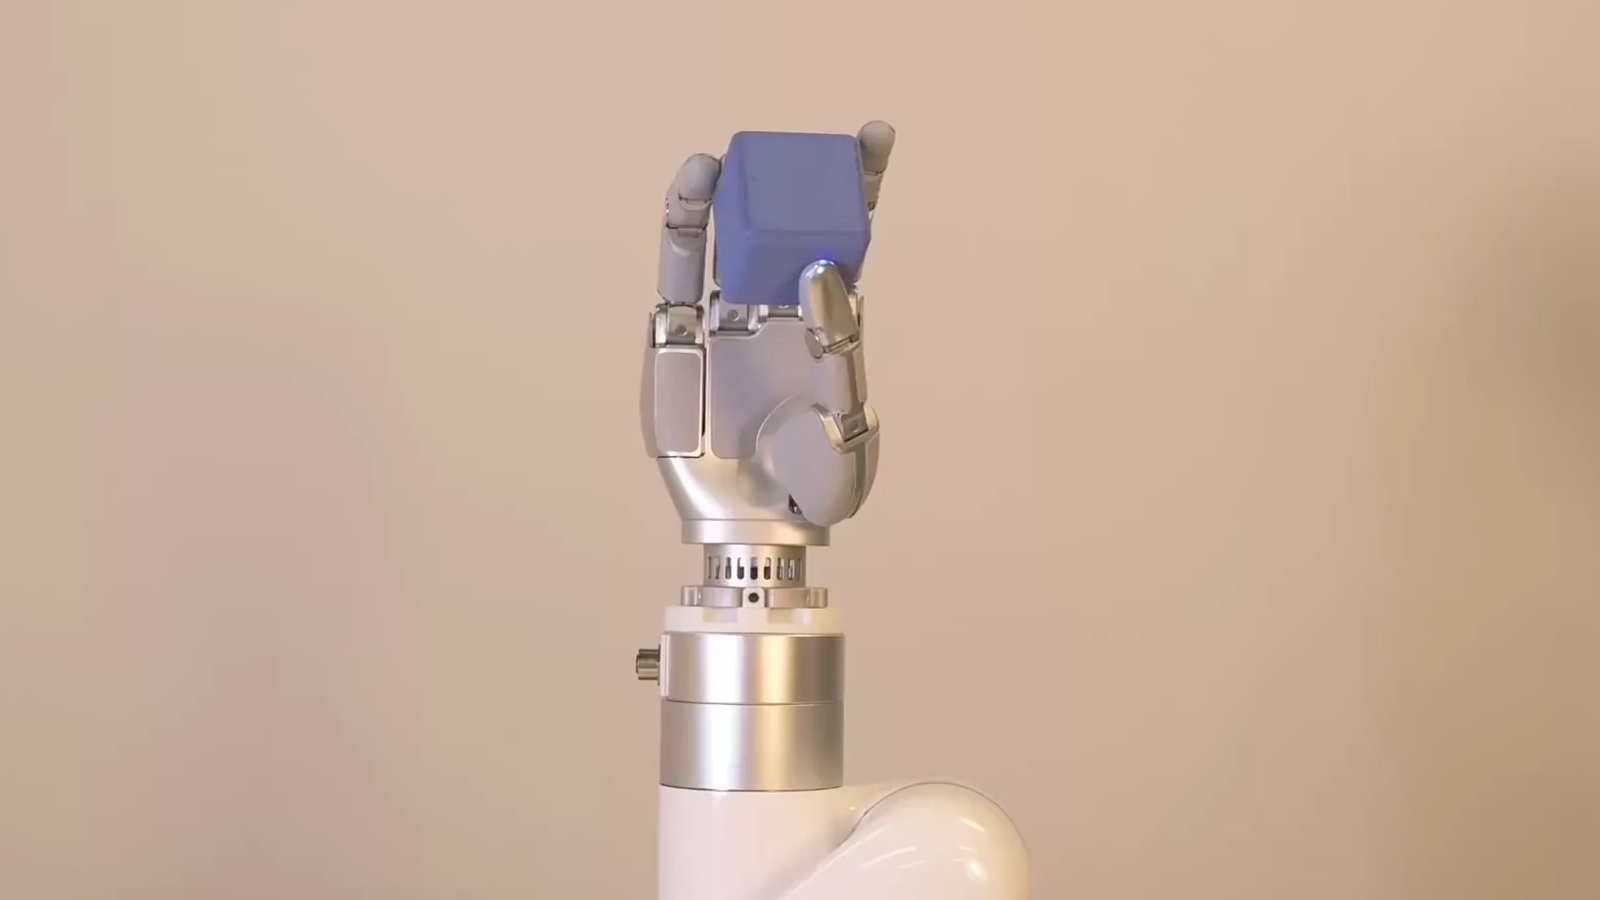](hand_retargeting.md#preview-live-motion) |
+| --- | --- | --- |
+| **[Hand retargeting](hand_retargeting.md)** Map tracked hand motion to robot joints. | **[Geometry-aware hand retargeting](hand_retargeting.md#inspect-object-contact)** Refine hands against object geometry. | **[Real-time hand teleoperation](hand_retargeting.md#preview-live-motion)** Drive a robot hand from live tracking. |
-| [](humanoid_retargeting.md) | [](humanoid_retargeting.md) |
-| --- | --- |
-| **[Humanoid retargeting](humanoid_retargeting.md)** Map captured body motion to humanoids. | **[Geometry-aware humanoid retargeting](humanoid_retargeting.md)** Account for terrain and contact. |
+| [](humanoid_retargeting.md) | [](humanoid_retargeting.md) | [](humanoid_retargeting.md) |
+| --- | --- | --- |
+| **[Humanoid retargeting](humanoid_retargeting.md)** Map captured body motion to humanoids. | **[Geometry-aware humanoid retargeting](humanoid_retargeting.md)** Account for terrain and contact. | **[Real-time humanoid teleoperation](humanoid_retargeting.md)** Drive a humanoid from live motion. |
-| [](full_body_retargeting.md) | [](full_body_retargeting.md#retarget-an-indoor-interaction) |
-| --- | --- |
-| **[Full-body retargeting](full_body_retargeting.md)** Combine body and hand motion. | **[Geometry-aware full-body retargeting](full_body_retargeting.md#retarget-an-indoor-interaction)** Preserve scene and object interactions. |
+| [](full_body_retargeting.md) | [](full_body_retargeting.md#retarget-an-indoor-interaction) | [](humanoid_retargeting.md#control-both-inspire-hands) |
+| --- | --- | --- |
+| **[Full-body retargeting](full_body_retargeting.md)** Combine body and hand motion. | **[Geometry-aware full-body retargeting](full_body_retargeting.md#retarget-an-indoor-interaction)** Preserve scene and object interactions. | **[Real-time full-body teleoperation](humanoid_retargeting.md#control-both-inspire-hands)** Drive body and hands together. |
## Quick links
diff --git a/docs/guide/quickstart.md b/docs/guide/quickstart.md
index 29930af..2816901 100644
--- a/docs/guide/quickstart.md
+++ b/docs/guide/quickstart.md
@@ -11,17 +11,21 @@ uvx --from 'retargetingkit[vis]' \
Open the Viser URL printed in the terminal. Select a robot and motion, then play or scrub the result. Replace `hand_retargeting` with any gallery below. Each preview records that gallery's Viser scene.
-| **`hand_retargeting`** Retarget tracked hands. | **`hand_neural`** Compare neural hand models. | **`hand_contact`** Refine hand-object contact. |
+|  |  |  |
| --- | --- | --- |
+| **`hand_retargeting`** Retarget tracked hands. | **`hand_neural`** Compare neural hand models. | **`hand_contact`** Refine hand-object contact. |
-| **`hand_object_dexmachina`** Explore DexMachina interactions. | **`hand_object_gigahands`** Explore GigaHands interactions. | **`hand_object_oakink2`** Explore OakInk2 interactions. |
+|  |  |  |
| --- | --- | --- |
+| **`hand_object_dexmachina`** Explore DexMachina interactions. | **`hand_object_gigahands`** Explore GigaHands interactions. | **`hand_object_oakink2`** Explore OakInk2 interactions. |
-| **`humanoid`** Browse motions and robot presets. | **`humanoid_contact`** Retarget object interactions. | **`humanoid_terrain`** Adapt motion to terrain. |
+|  |  |  |
| --- | --- | --- |
+| **`humanoid`** Browse motions and robot presets. | **`humanoid_contact`** Retarget object interactions. | **`humanoid_terrain`** Adapt motion to terrain. |
-| **`full_body_hoi`** Retarget body and hand interactions. | **`full_body_hsi`** Retarget body motion in furnished scenes. |
+|  |  |
| --- | --- |
+| **`full_body_hoi`** Retarget body and hand interactions. | **`full_body_hsi`** Retarget body motion in furnished scenes. |
To list gallery module names from an installed checkout, run `uv run python -m retargetingkit.gallery`. Gallery data, robot models, and checkpoints download on first use; complete [asset setup](assets.md) first.
diff --git a/docs/guide/teleoperation.md b/docs/guide/teleoperation.md
index 5f0abeb..f2e8037 100644
--- a/docs/guide/teleoperation.md
+++ b/docs/guide/teleoperation.md
@@ -1,5 +1,9 @@
# Teleoperation
+|  |  |
+| --- | --- |
+| Dexterous hand control. | Humanoid motion control. |
+
A named rig connects a source, retargeter, and target in one command. Choose the flow that matches the motion you want to control, then complete the linked device setup.
## Choose a flow
diff --git a/docs/reference/sources/pico.md b/docs/reference/sources/pico.md
index 597c1e7..cbd5c41 100644
--- a/docs/reference/sources/pico.md
+++ b/docs/reference/sources/pico.md
@@ -1,6 +1,6 @@
# PICO
-
+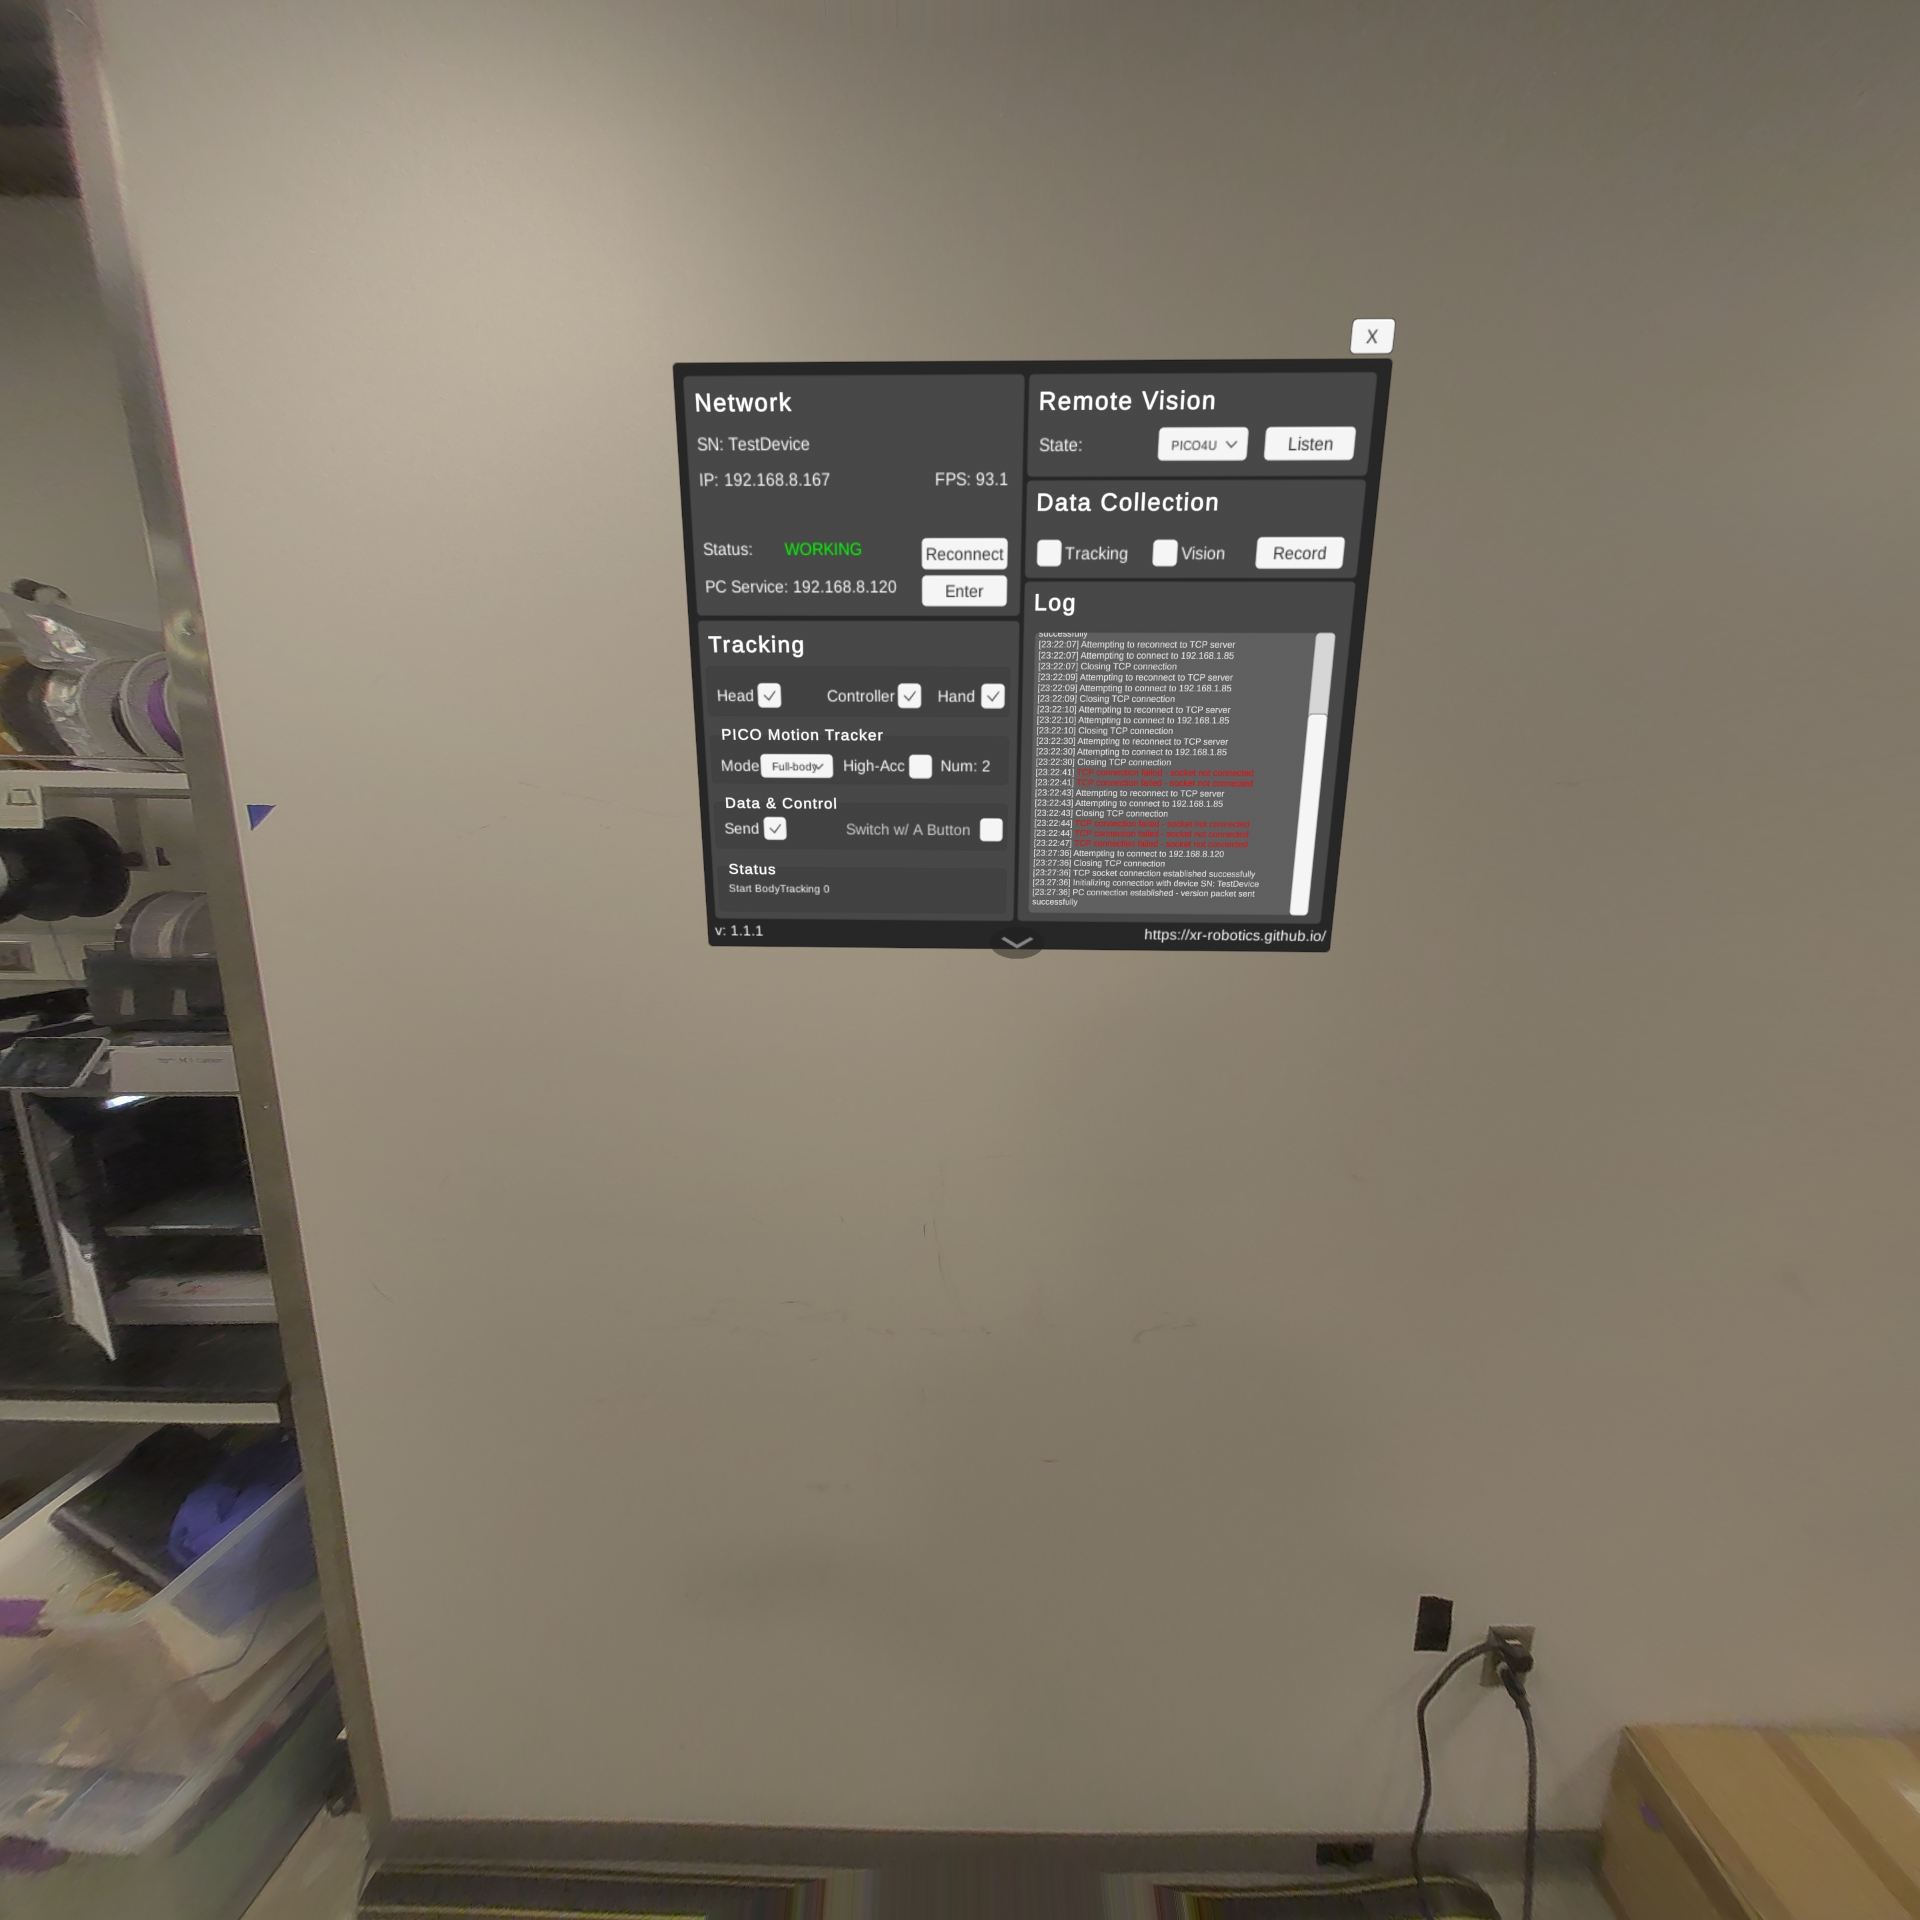
Use PICO full-body tracking through XRoboToolkit to retarget a 24-joint body to Unitree G1. Record sessions for offline replay, or use controller buttons to open and close two Inspire hands alongside body motion.
diff --git a/docs/reference/sources/quest3.md b/docs/reference/sources/quest3.md
index 1fab2f1..6c8960e 100644
--- a/docs/reference/sources/quest3.md
+++ b/docs/reference/sources/quest3.md
@@ -1,6 +1,6 @@
# Quest 3
-
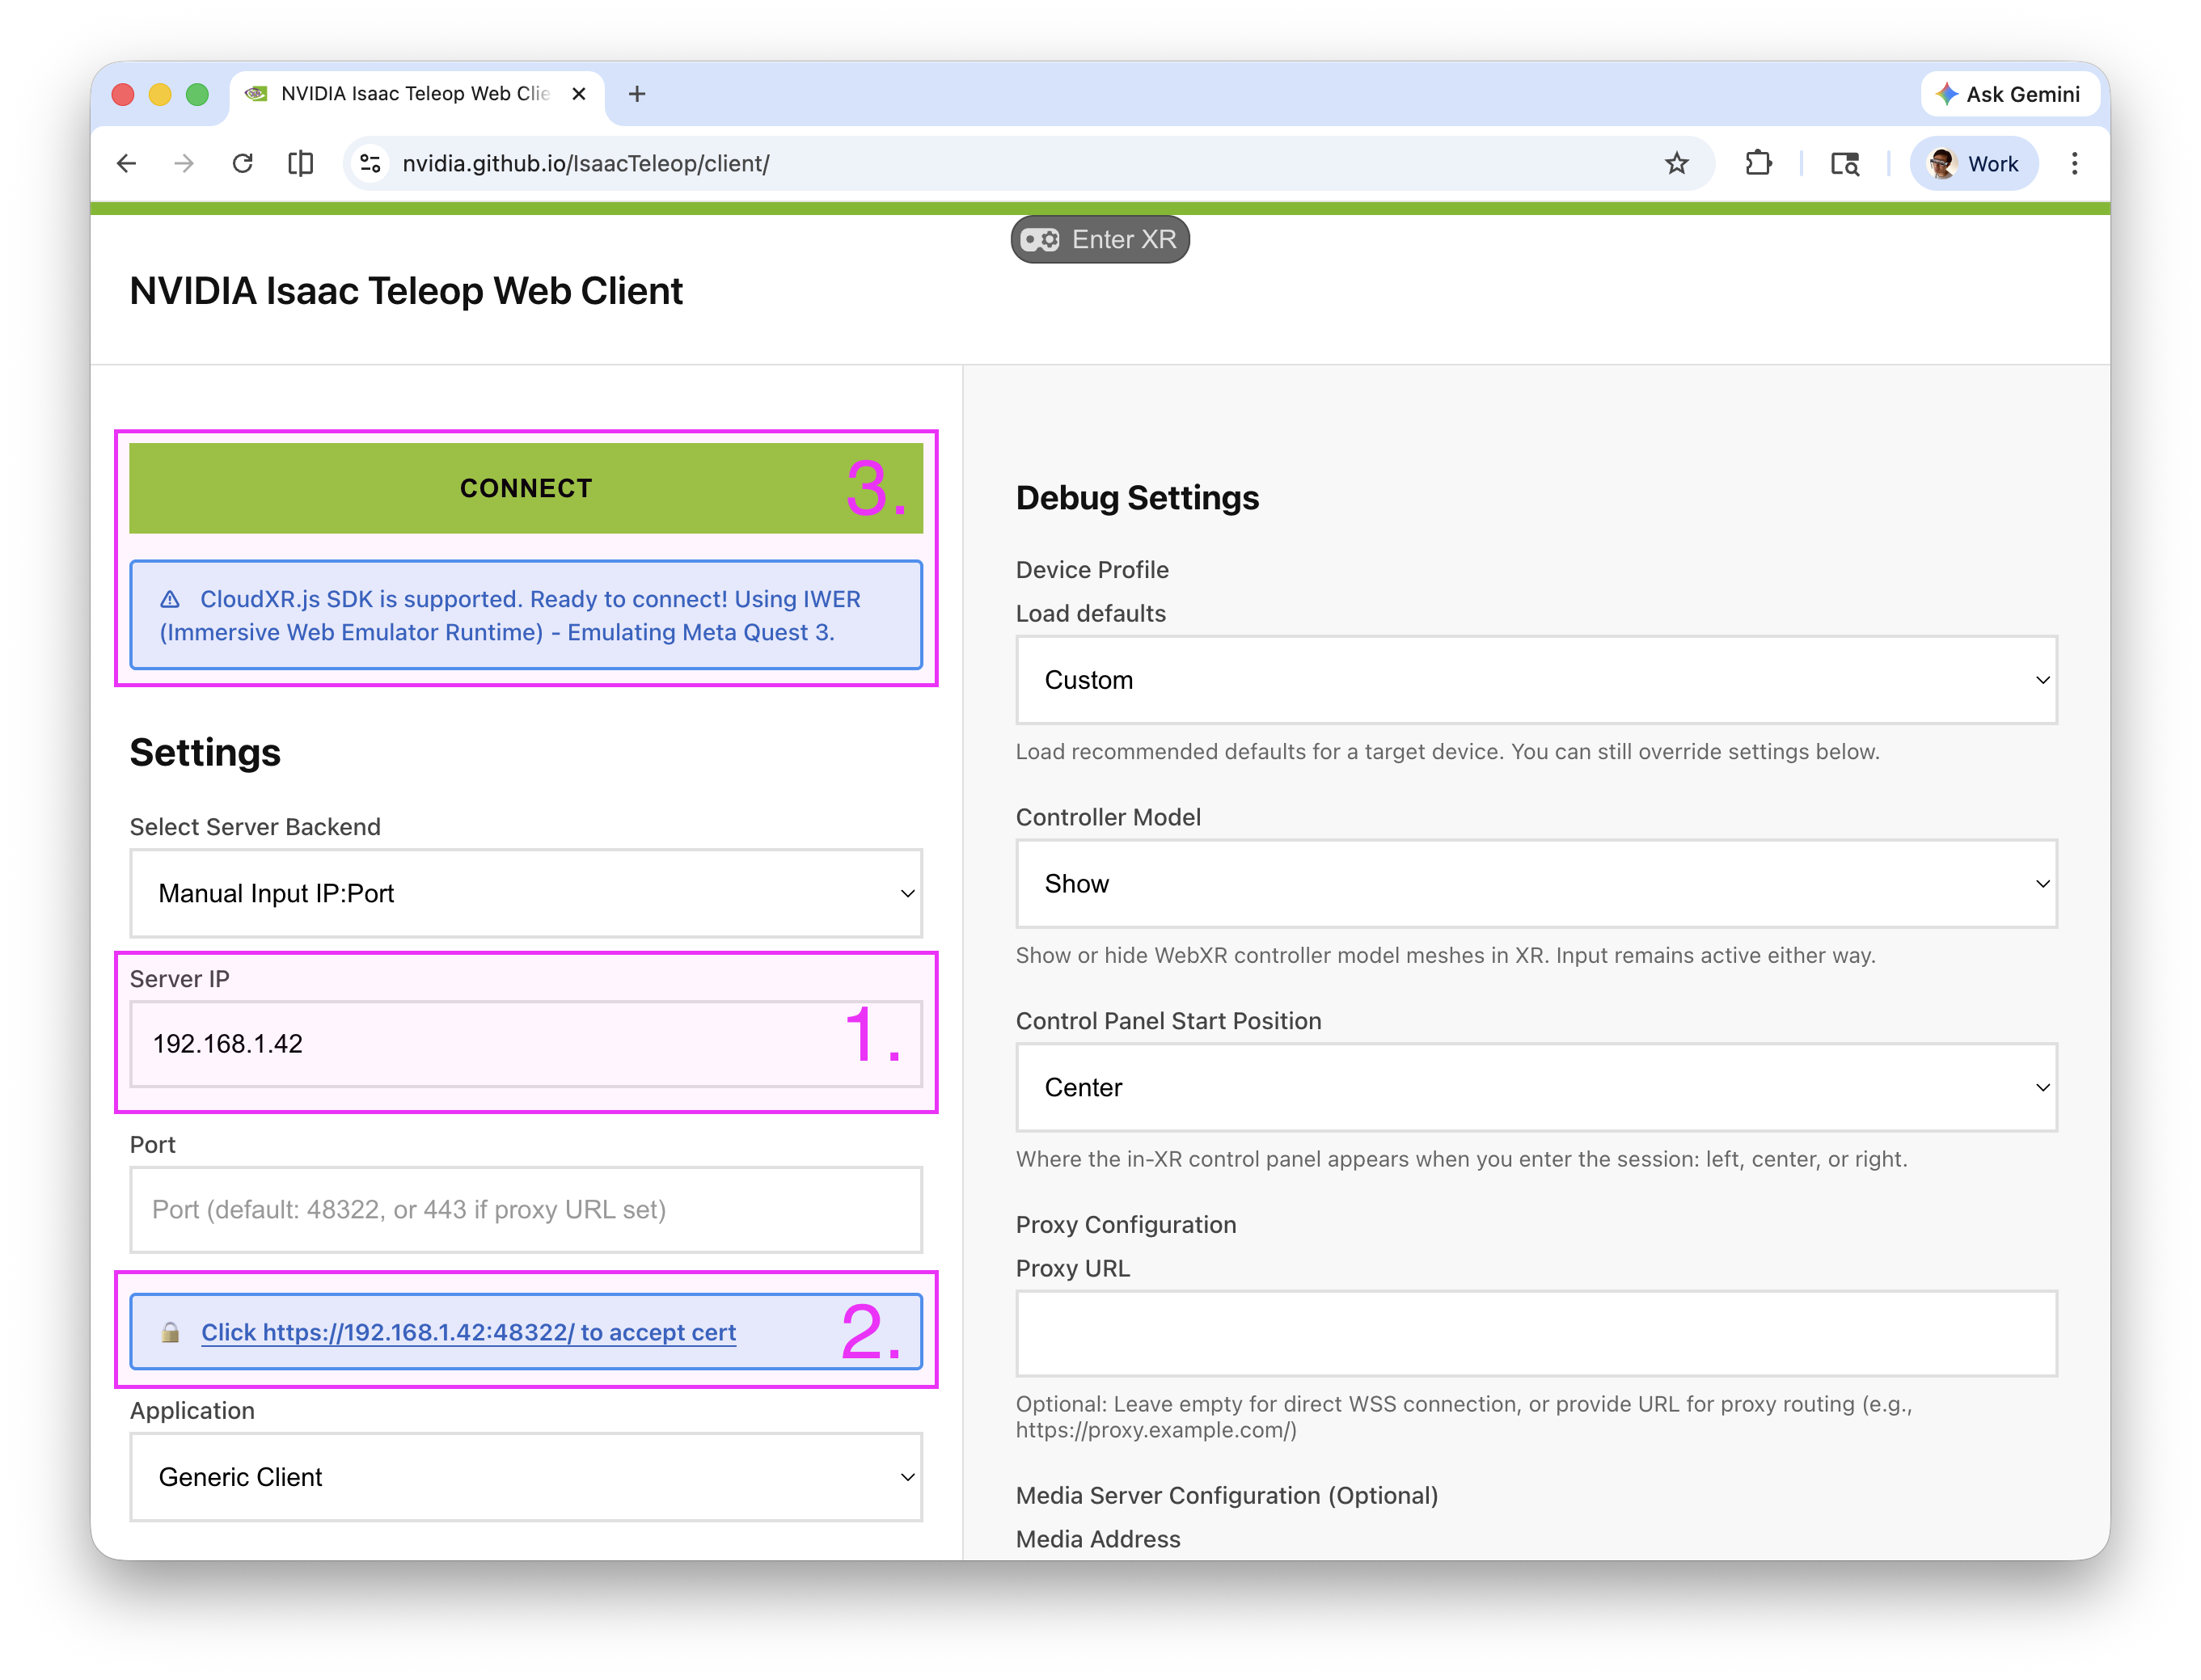
+
Use Quest 3 controllers to move one or two xArm6 or xArm7 end effectors. Tracking comes through NVIDIA Isaac Teleop and CloudXR. The standalone playground supports a Viser preview, controller calibration, and hardware control.
@@ -30,7 +30,7 @@ sudo ufw allow 49100,48322/tcp
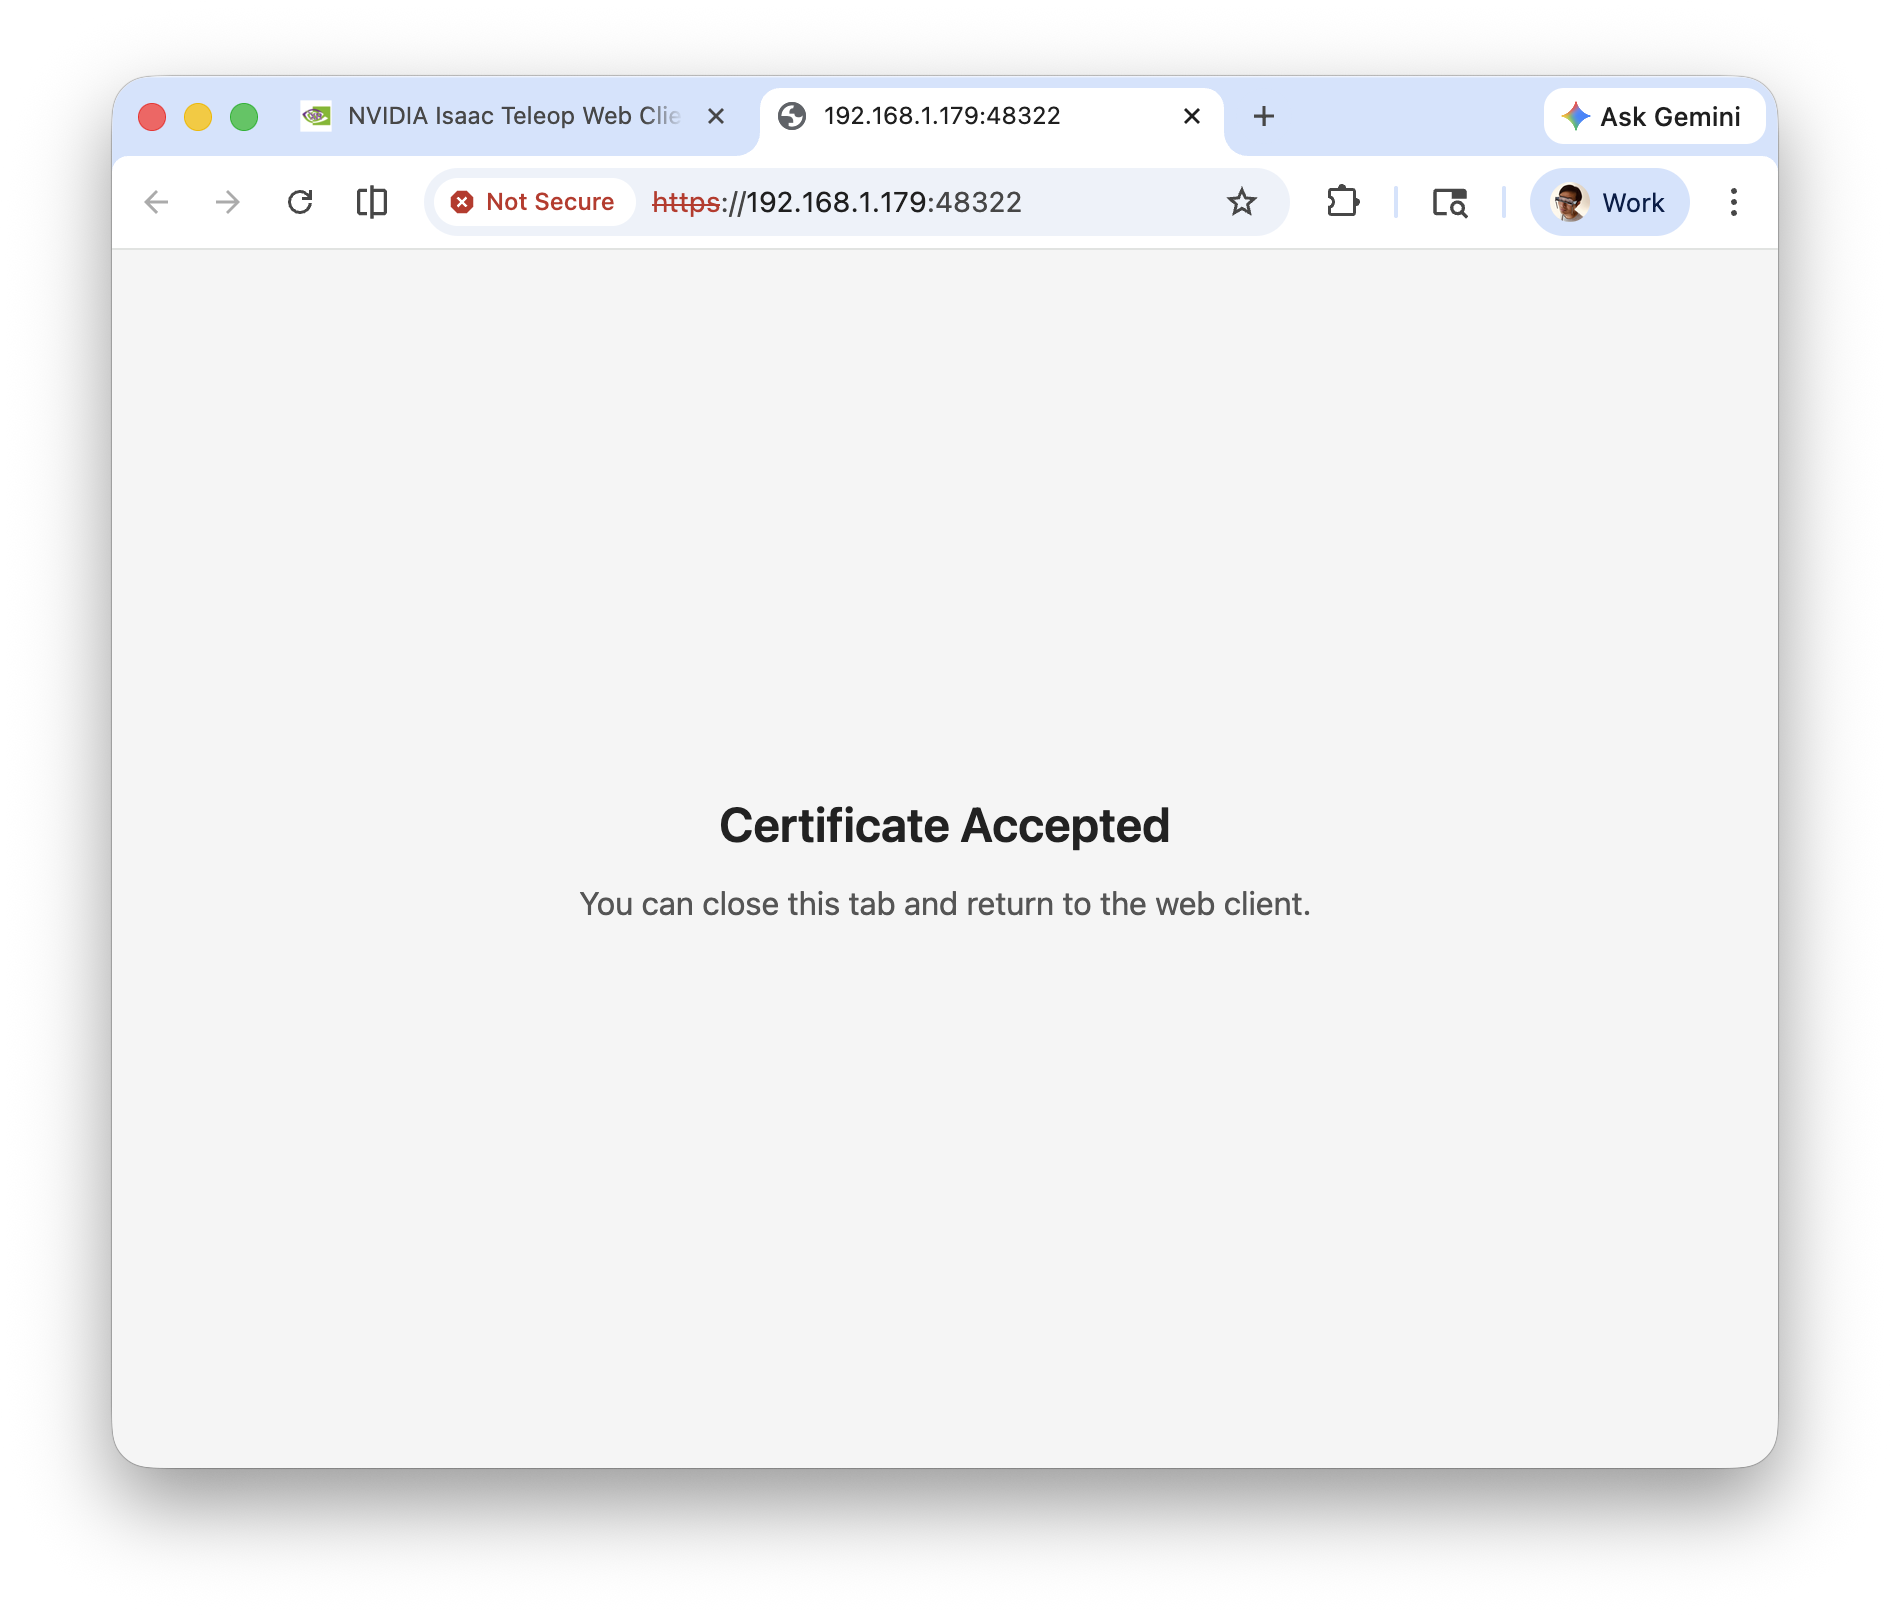
Open the [Isaac Teleop WebXR client](https://nvidia.github.io/IsaacTeleop/client) in the headset browser. Enter the workstation IP, accept its generated certificate, and select **Connect**, then **Play**.
-
+
## Check tracking
@@ -77,8 +77,8 @@ Use `--arm xarm6` to select xArm6. Each arm moves to its home pose during startu
## Keep the headset awake
-
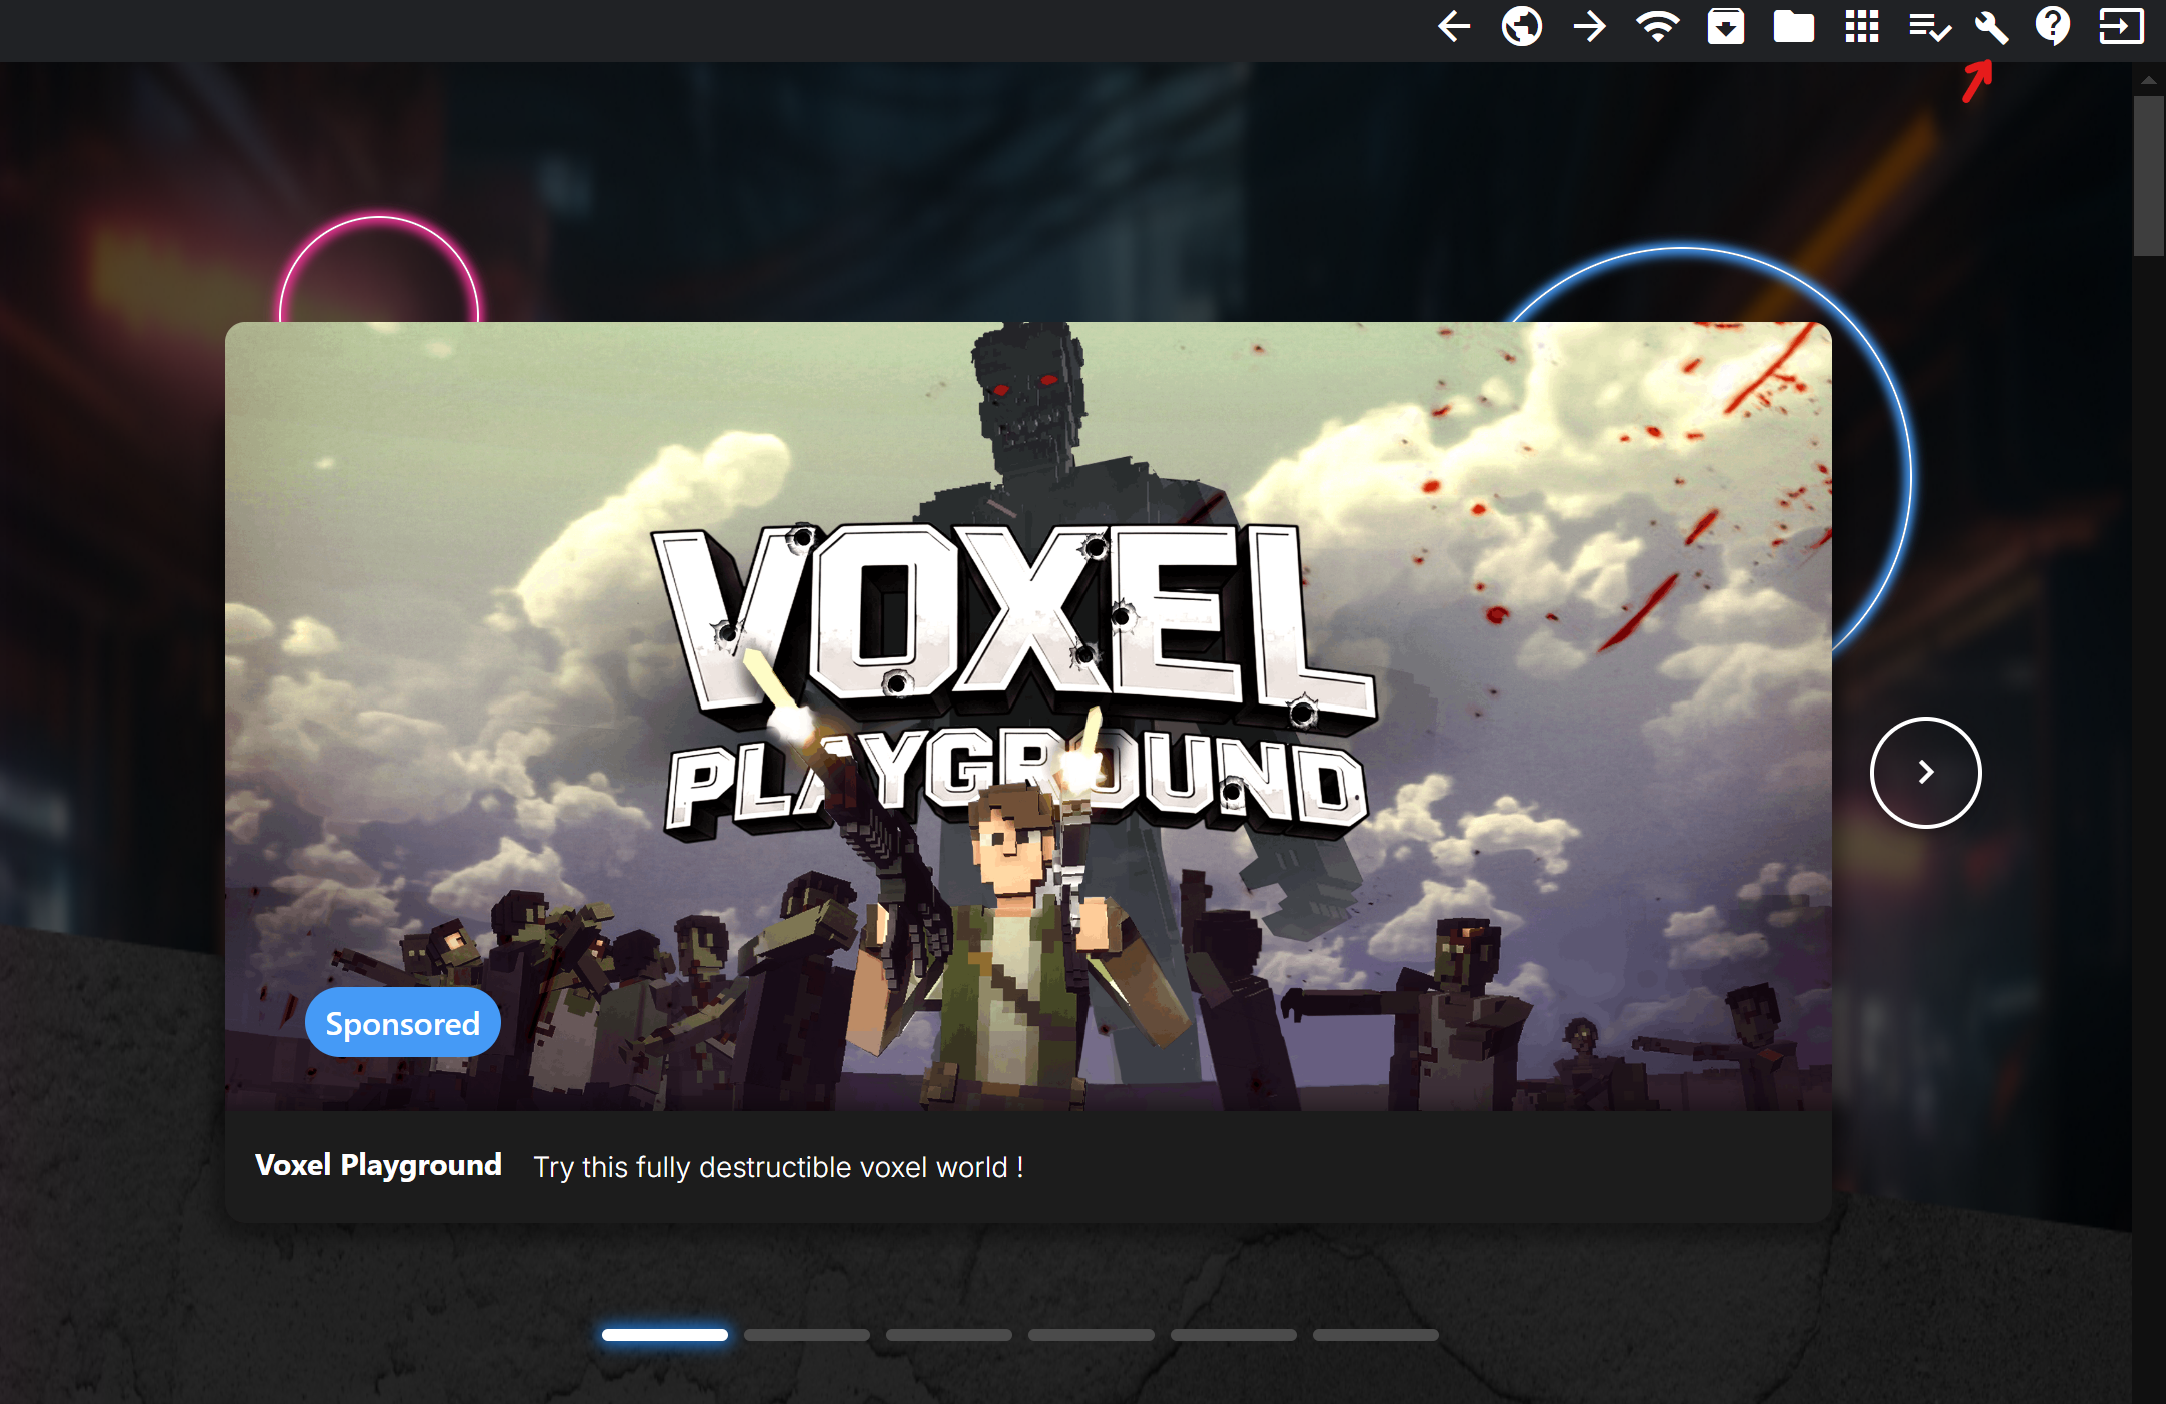
+
-
+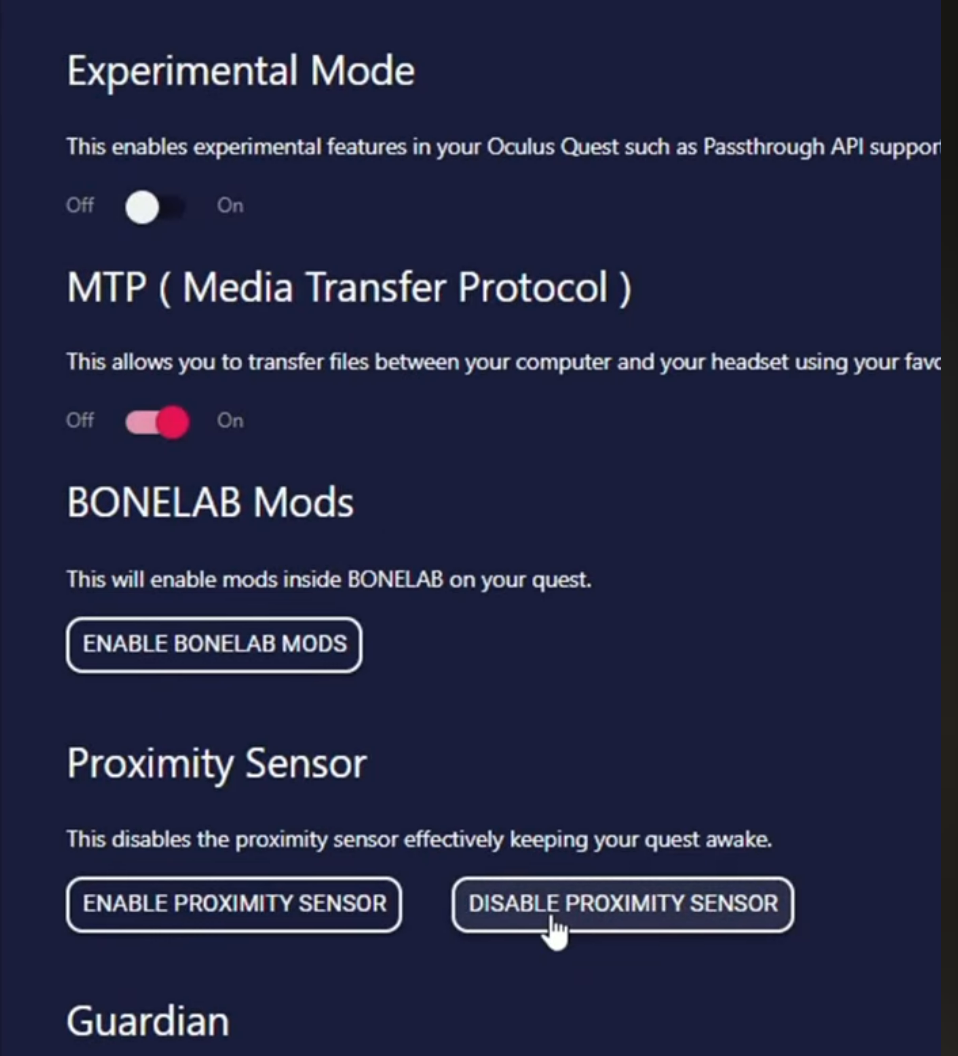
For long sessions, enable developer mode, connect SideQuest over USB, and disable the proximity sensor in **Device Settings & Tools**.
diff --git a/docs/reference/sources/vision_pro.md b/docs/reference/sources/vision_pro.md
index 8bd4d11..c661230 100644
--- a/docs/reference/sources/vision_pro.md
+++ b/docs/reference/sources/vision_pro.md
@@ -1,6 +1,6 @@
# Apple Vision Pro
-
+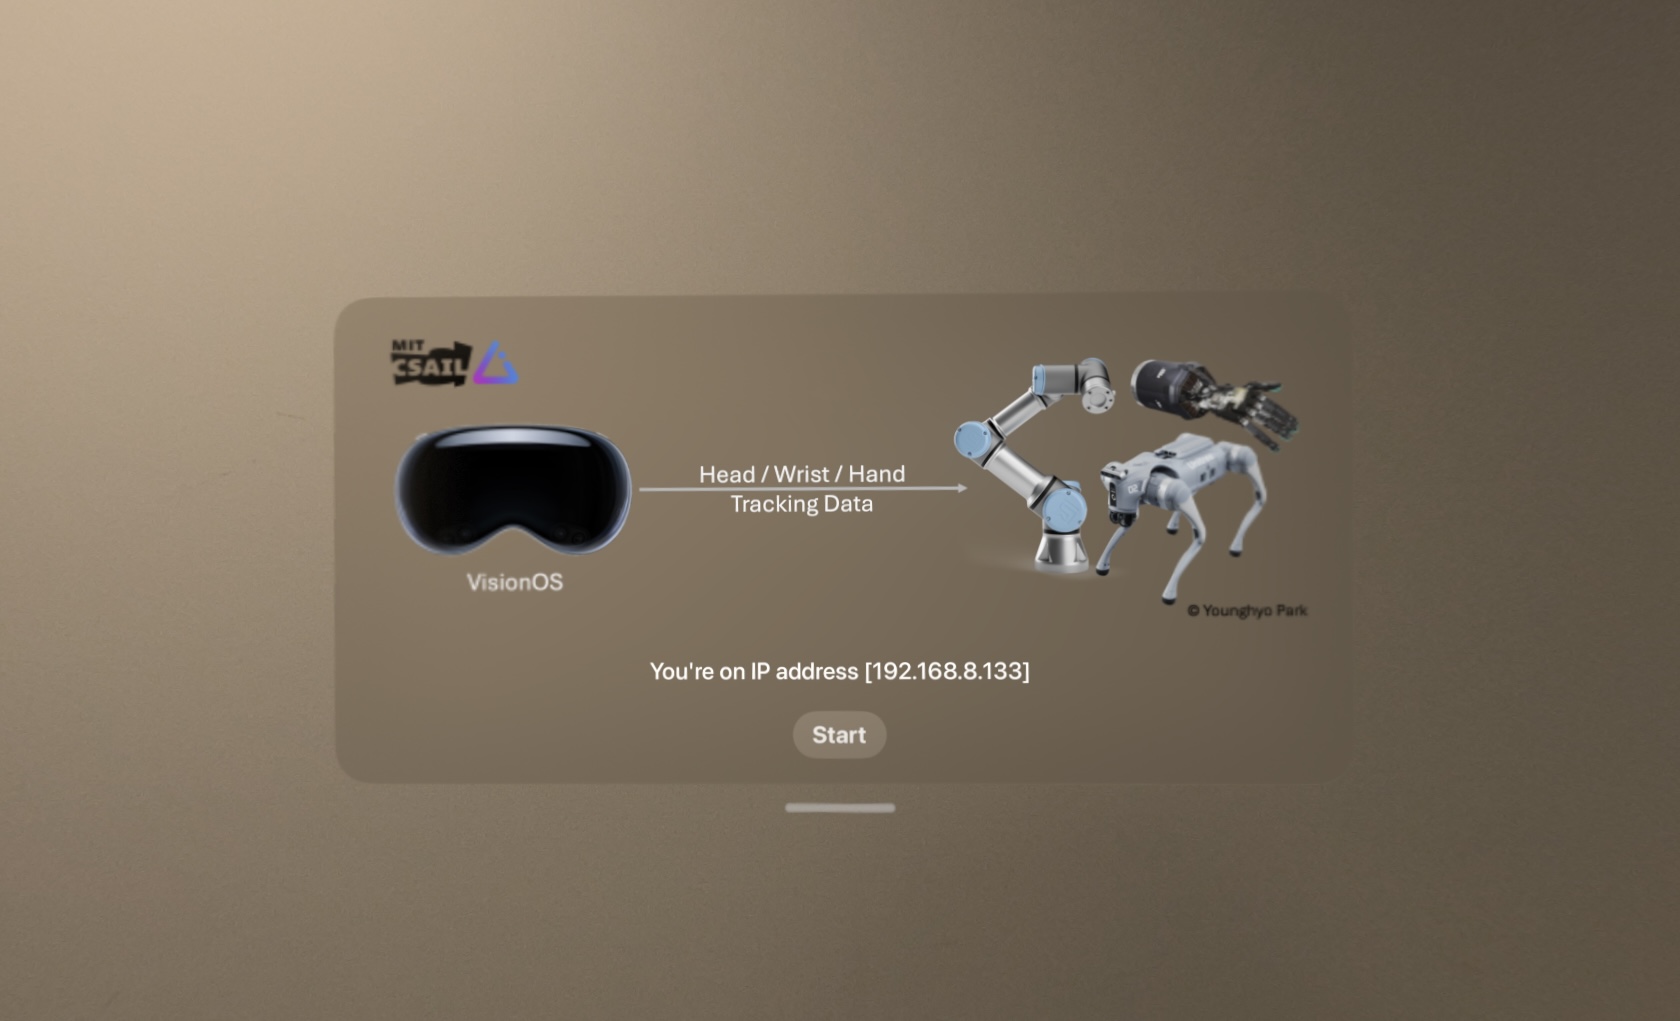
Stream head, wrist, and finger tracking from Apple Vision Pro with `avp_stream`. RetargetingKit can drive robot hands, robot arms, or synchronized arm-and-hand assemblies, and replay the same tracking from a recording.
@@ -12,7 +12,7 @@ Stream head, wrist, and finger tracking from Apple Vision Pro with `avp_stream`.
## Connect the headset
-
+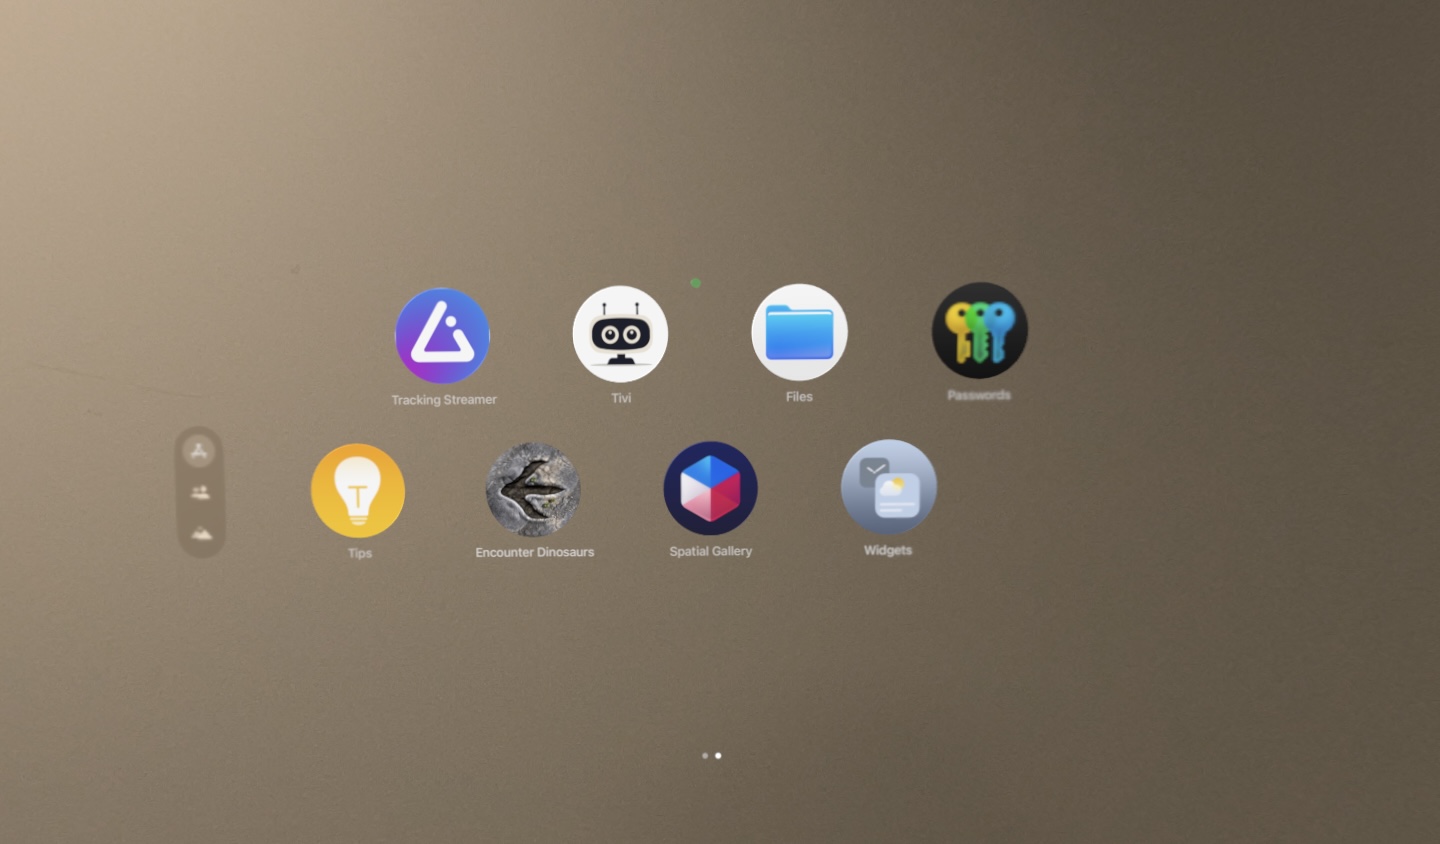
1. Connect the workstation and Vision Pro to the same Wi-Fi network.
2. Open **Tracking Streamer** on Vision Pro.